Can Autoregressive Sampling Solve Physical Tasks? Aether AI's Path to Causal Reasoning

Causal reasoning and discrete inference, not autoregressive sampling, are the key to autonomous robots.
Starting from a tweet, the article explores the fundamental limitations of autoregressive sampling in the physical world. Autoregressive models rely on statistical correlations for approximate pattern matching, excelling in discrete symbol spaces like language, but physical tasks require precise causal chains and real-time constraints, where any single-step deviation is amplified by physical laws. The article argues that for autonomous robots to truly be deployed, causality and discrete reasoning must be reinjected into the inference loop—yet current end-to-end learning paradigms marginalize these capabilities. Aether AI is described by the original author as doing the foundational, non-consensus work the field truly needs, likely involving deep integration of symbolic reasoning, causal models, and neural networks.
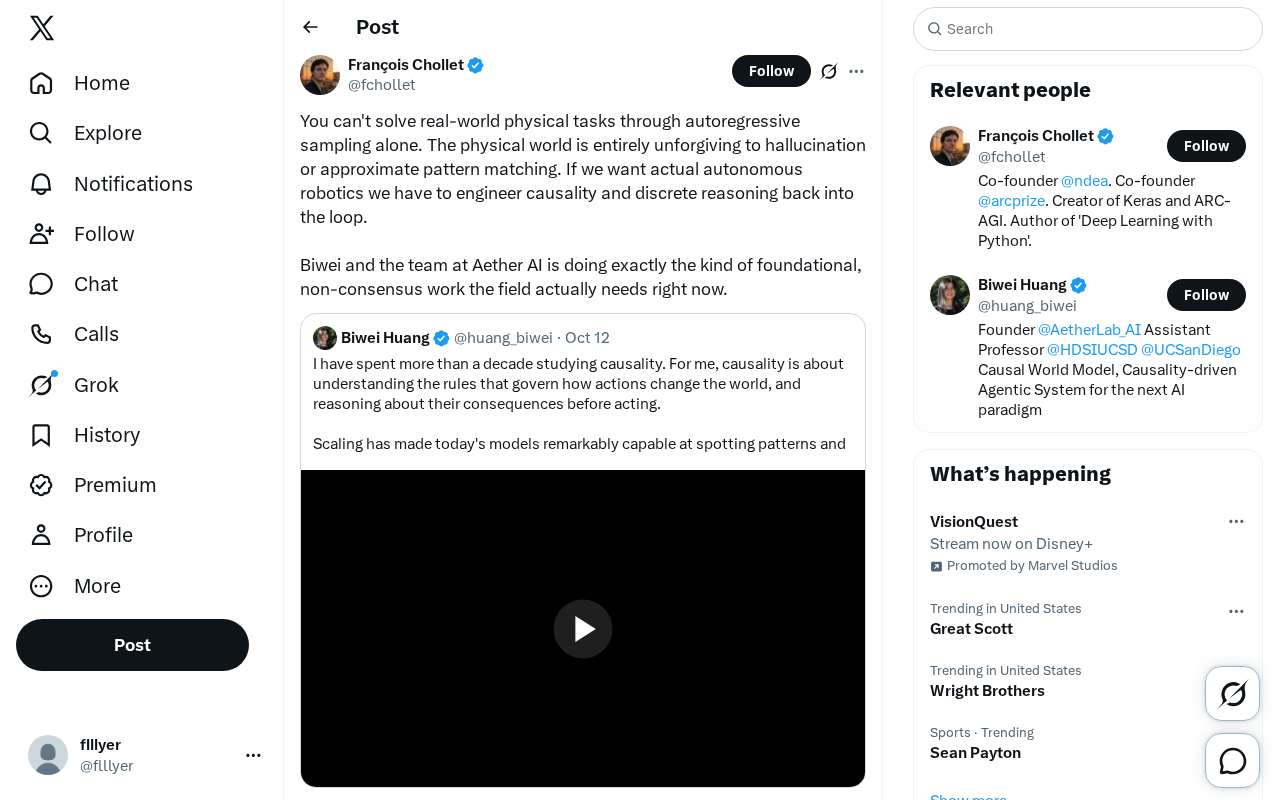
Autoregressive sampling can generate fluent text, but it can't help a robot stand firm in the real world. The physical world has zero tolerance for hallucination or approximate pattern matching—a view that captures the core tension between current AI and robotics.
Why Autoregressive Models Can't Handle the Physical World
The essence of autoregressive sampling is predicting the next token based on the existing sequence. It performs stunningly well in discrete symbol spaces like language and images, but physical tasks don't offer that kind of flexibility.
In the real world, a robot arm's angular deviation or a grasping force error will be mercilessly amplified by physical laws. Language models can be "roughly right," but the physical world demands precise causal chains. Approximate pattern matching may be harmless when generating text, but when controlling a robot it can directly cause task failure or even hardware damage.
The original text points out: "The physical world is entirely unforgiving to hallucination or approximate pattern matching." This is not a rejection of large language models, but a clear-eyed recognition of their capability boundaries.
Autoregressive Sampling is the core mechanism of a class of generative models: the model predicts the next element in a sequence one by one based on all previously generated elements. GPT-series language models, PixelCNN in image generation, and WaveNet in audio generation all adopt this paradigm. Its mathematical foundation is the chain rule—decomposing the joint probability into a product of conditional probabilities, thereby breaking down a high-dimensional generation problem into a series of tractable single-step predictions.
The advantage of autoregressive models is that, given enough training data and sufficient model capacity, they can approximate arbitrarily complex distributions in discrete symbol spaces. But this advantage comes at a cost—they are essentially learning statistical correlations, not causal mechanisms. When the environment allows ambiguity (such as writing poetry or small talk), this approximation is entirely sufficient; but when the environment is governed by strict physical laws, any single-step deviation accumulates exponentially with sequence length, ultimately leading to catastrophic failure. This is precisely the fundamental bottleneck that autoregressive sampling encounters in robot control scenarios.
Causal Reasoning: The Overlooked Infrastructure
For autonomous robots to truly be deployed, causality and discrete reasoning capabilities must be reinjected into the inference loop.
The current end-to-end learning paradigm tends to use large-scale data to drive statistical correlations, but physical tasks require:
- Discrete decisions: Robots need to make clear choices between "grasp" and "don't grasp," rather than fuzzy sampling from continuous probability distributions.
- Causal chains: Every action changes the environment state, and the next decision must be based on explicit modeling of causes and effects.
- Real-time constraints: Physical interactions have hard time windows and cannot iterate indefinitely like text generation.
These problems are not new discoveries, but they have been marginalized in the wave of autoregressive models' rapid advancement.
Causal Inference differs from statistical correlation in its core: the former models "intervention effects" and "counterfactuals," while the latter merely characterizes co-occurrence patterns among variables. In robot scenarios, this distinction is crucial—what the robot needs to answer is not "is there a correlation between the grasping action and success," but "if I apply this torque right now, how will the object move."
The Structural Causal Model (SCM) proposed by Judea Pearl provides a formal framework for such problems: explicitly representing causal dependencies among variables through directed acyclic graphs (DAGs), and distinguishing three levels—"observation," "intervention," and "counterfactual." Most current end-to-end deep learning remains at the first level (observation level), i.e., fitting P(Y|X) from data, while physical tasks truly require second-level or even third-level capabilities. Discrete reasoning is complementary to causal reasoning: it requires making clear choices within a finite action space, rather than sampling from continuous distributions. Combining discrete symbol manipulation with continuous neural network representations is the core challenge of current Neuro-Symbolic research.
Aether AI: Non-Consensus Foundational Research
The original author specifically mentions Biwei and the Aether AI team, calling their work "foundational, non-consensus work the field actually needs right now."
The term "non-consensus" carries significant weight. In the AI field, massive resources flow toward directions that are scalable and quickly verifiable, while foundational causal reasoning and discrete reasoning research often does not attract capital and public attention. But it is precisely this kind of work that may constitute the key piece for autonomous robots to move from the laboratory to real-world scenarios.
Aether AI's specific technical approach has not yet been elaborated in the original text, but inferring from context, its direction likely involves deeply integrating symbolic reasoning, causal models, and neural networks, rather than simply scaling up model size.
Implications for Industry Direction
The thinking triggered by this tweet goes beyond the technology itself—it touches on the choice of industry direction.
If physical tasks truly cannot be solved by autoregressive sampling, then the many teams currently investing heavily in embodied AI may need to re-examine their tech stacks. Simply stuffing a language model into a robot body may not produce true autonomy.
Conversely, those seemingly "slow" foundational research areas—causal discovery, discrete optimization, interpretable decision-making—may be the source of long-term competitiveness.
Of course, this does not mean a wholesale rejection of autoregressive models. They still have irreplaceable value in high-level abstractions such as task planning and human-robot interaction. The key is to apply the right tools at the right levels.
Embodied AI has been a hot direction in recent years, with the core claim that intelligence cannot exist apart from a body, and that an agent must learn through interaction with the environment. This idea itself is reasonable, but many current embodied AI projects adopt a simple concatenation approach of "large language model + robot body"—using LLMs for task planning, pretrained vision models for perception, and reinforcement learning or imitation learning for low-level control.
The problem is: this architecture lacks explicit causal interfaces between modules. LLMs output symbolic action commands, low-level controllers execute continuous torques, and the mapping between the two often relies on fitting large amounts of data rather than causal models. The result is that the system performs adequately in-distribution, but once it encounters physical perturbations unseen in training (such as friction changes or object deformation), it quickly collapses. True autonomy requires not just a "perception-planning-control" pipeline, but causal consistency across all levels—high-level decisions must understand the physical consequences of low-level actions, and low-level execution must be able to feed causal information back to the high level.
Conclusion
The harshness of the physical world dictates: approximately correct is not enough—it must be causally correct. The path Aether AI has chosen may not be mainstream, but the direction is worth watching.
Related articles

Chain of Thought Isn't Just for AI: How Humans Can Use CoT to Improve Thinking Quality
Chain of Thought isn't just a prompt trick for large models. Starting from a Hacker News discussion, this article analyzes why CoT works for human thinking too, breaks down actionable ways to transfer it, and highlights the key differences between human CoT and machine CoT.
Cloudflare Teams Up with OpenAI: Closi…
Cloudflare Teams Up with OpenAI: Closing the Loop from Vulnerability Discovery to Defense with AI
Cloudflare uses OpenAI Daybreak to investigate security vulnerabilities and generate reviewable remediation plans, while developers use Codex to boost coding efficiency and quality.

Orca Multi-Agent Orchestration in Practice: A Guide to Parallel Collaboration with Claude and Codex
Orca is Stable AI's free open-source agent workbench supporting 34 agents like Claude Code and Codex in parallel. Learn its Git worktree isolation, multi-model orchestration, and mobile management.