Robot Joint Precision Bottlenecks: A Selection Guide for High-Accuracy Rotary Encoders

A systematic guide to selecting high-accuracy rotary encoders for robot joints, from error analysis to calibration.
This article addresses the common challenge of achieving sub-0.5-degree accuracy in robot joint encoders. It clarifies the critical distinction between resolution and accuracy in magnetic encoders like the AS5048, compares optical, inductive, and resolver technologies, and emphasizes that mechanical errors and kinematic calibration often matter more than sensor upgrades alone.
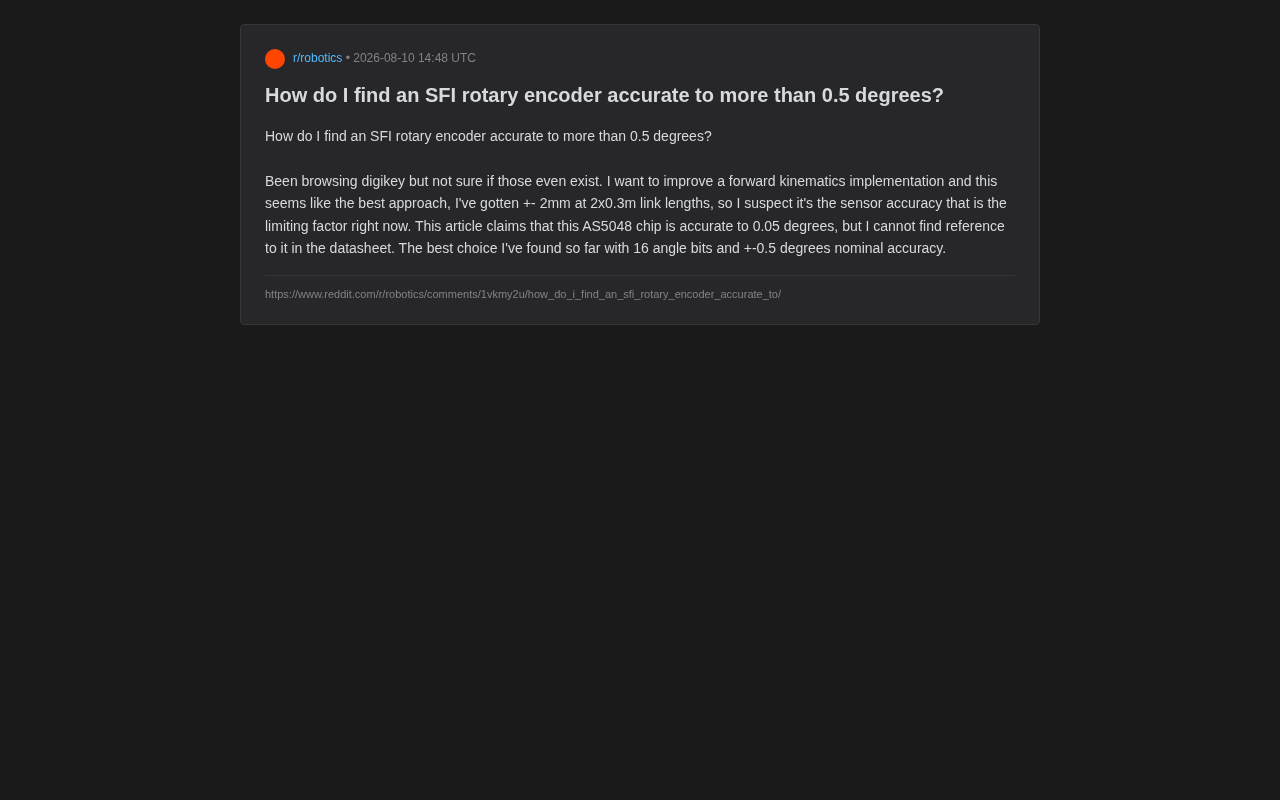
In the fields of robot kinematics and automation control, end-effector positioning accuracy often depends on the quality of the lowest-level sensors. Recently, a developer posted a highly representative question in a technical community: how to find a rotary encoder with accuracy better than 0.5 degrees to improve their Forward Kinematics implementation. This seemingly simple component selection question actually involves a complex interplay between sensor accuracy, mechanical structure, and algorithmic errors.
Deriving Sensor Accuracy Requirements from End-Effector Error
The developer's scenario involves a typical two-link robotic arm system. Using two 0.3-meter (0.3m) links and forward kinematics to calculate end-effector position, they ended up with a positioning error of ±2mm. After analysis, they determined that the limiting factor was the angular accuracy of the sensor (i.e., the encoder), rather than the algorithm itself.
Forward Kinematics is one of the most fundamental mathematical tools in robotics. Its core task is: given all joint angle values, calculate the position and orientation of the end-effector in Cartesian space. For serial manipulators, this is typically achieved through the Denavit-Hartenberg (DH) parameter method, building a chain of homogeneous transformation matrices — each joint corresponds to a 4×4 transformation matrix, and multiplying all matrices sequentially yields the end-effector pose relative to the base. The forward kinematics computation itself is deterministic and unambiguous (unlike inverse kinematics), so its output accuracy depends almost entirely on the input parameters — namely the accuracy of joint angle measurements and geometric parameters.
This assessment is engineering-sound. In serial manipulators, small errors in joint angles are amplified by link lengths at the end-effector. For a 0.3-meter link, a 0.5-degree angular error translates to approximately:
0.3m × sin(0.5°) ≈ 0.3 × 0.0087 ≈ 2.6mm
With error accumulation across two joints, the ±2mm end-effector error falls squarely within the range explainable by ±0.5-degree encoder accuracy. This confirms his assessment — to further improve end-effector precision, one must start by improving angular sensing accuracy.
Encoder Resolution vs. Accuracy: The Two Most Commonly Confused Concepts
The developer mentioned the AMS AS5048 magnetic encoder chip, citing an article claiming it achieves 0.05-degree accuracy, but couldn't find corresponding specifications in the official datasheet. This actually reveals an extremely common misconception in sensor selection — confusing Resolution with Accuracy.
How Magnetic Encoders Work
Before diving into the accuracy discussion, it's important to understand the basic working mechanism of magnetic encoders. The core principle of magnetic rotary encoders is using the Hall effect or magnetoresistive effect to detect angular changes in a rotating magnetic field. The typical structure involves fixing a diametrically magnetized cylindrical magnet on the rotating shaft, with an IC chip integrating multiple Hall sensor arrays placed directly above or below the magnet. As the magnet rotates with the shaft, the sensor array on the chip detects sinusoidal/cosinusoidal magnetic field components, then uses an internal CORDIC algorithm to calculate the arctangent, yielding the absolute angle. The AMS (now merged into ams-OSRAM) AS5048 series is a representative product of this type. Magnetic encoders offer advantages including non-contact measurement, small size, low cost, and insensitivity to dust and oil contamination, but their accuracy is limited by magnetic field uniformity, temperature drift, magnet magnetization quality, and mounting alignment precision.
Resolution Does Not Equal Accuracy
The AS5048 provides 14-bit resolution, theoretically dividing 360 degrees into 16,384 counts, with each count representing approximately 0.022 degrees. This is the origin of the "0.05 degree" figure — it's the resolution, representing the smallest angular increment the sensor can distinguish.
However, accuracy measures the deviation between the measured value and the true value. The actual accuracy stated in the AS5048 datasheet (considering Integral Non-Linearity, INL) is typically around ±0.5 degrees. Integral Non-Linearity (INL) is a key metric for evaluating encoder accuracy, describing the maximum cumulative deviation between the encoder's actual angular output and the ideal linear relationship. Specifically, if you plot the encoder's ideal output as a perfect straight line from 0 to 360 degrees, INL is the maximum distance the actual transfer function curve deviates from this line (expressed in degrees). For magnetic encoders, INL primarily stems from non-uniformities in magnetic field distribution, manufacturing deviations in the sensor array, and non-idealities in the chip's internal signal processing. Notably, INL is a systematic error with repeatability, so it can theoretically be partially compensated through calibration lookup tables.
This means that even though you can read a number with 0.022-degree granularity, that number itself may deviate from the true angle by up to half a degree. Therefore, the article's claim of "0.05-degree accuracy" was actually a misreading of the resolution parameter.
The developer's mention of "16 angle bits, ±0.5-degree nominal accuracy" is indeed the best magnetic encoder option he could find, which aligns with the physical limits of magnetic encoder technology.
Technical Paths to Breaking the 0.5-Degree Accuracy Barrier
If the ±0.5-degree ceiling of magnetic encoders has been reached, achieving higher accuracy typically requires upgrading the technology approach.
Optical Encoders
Optical encoders measure angles through grating lines on a code disc, and their accuracy is typically far superior to magnetic encoders. The working principle uses a light source (usually an LED or laser diode) to illuminate a code disc with precision grating patterns. The light transmitted or reflected is received by a photodetector array, and the rotation angle is determined by analyzing changes in the light/dark fringe patterns. Incremental optical encoders output A/B quadrature pulse signals, tracking relative angular changes by counting pulses; absolute optical encoders have Gray code or pseudo-random code patterns etched on their discs, allowing direct readout of absolute position at any time without requiring a reference point.
High-end absolute optical encoders can achieve 17-23 bit resolution, with accuracy controlled to 0.01 degrees or better. Through interpolation techniques, resolution can be further enhanced by hundreds of times within a single grating period. Industrial-grade optical encoders (from brands like Heidenhain, Renishaw, etc.) can achieve ±1 arc-second (approximately 0.0003 degrees) accuracy, though such products often cost hundreds to thousands of dollars. The trade-offs are larger size, higher cost, and greater sensitivity to dust and vibration. For laboratory-grade robotic arms pursuing ultimate precision, this is the mainstream choice.
Inductive Encoders
Inductive encoders that have emerged in recent years (such as CUI Devices' AMT series or some Renishaw products) achieve a good balance between contamination resistance and accuracy. Some models achieve accuracy within 0.1 degrees at prices more affordable than high-end optical encoders. Inductive encoders use electromagnetic induction principles, generating eddy currents in conductive patterns on the rotor through excitation coils, then determining the angle by detecting amplitude and phase changes in the induced signal via receiver coil arrays. This technology combines the environmental robustness of magnetic encoders with accuracy approaching that of optical encoders, making it an increasingly popular choice for mid-to-high-end applications.
Resolvers
Industrial servo systems commonly use resolvers, which offer extremely strong resistance to harsh environments (operating in temperature ranges from -55°C to +175°C, withstanding intense vibration and radiation), but require additional decoding circuitry (RDC chips, such as Analog Devices' AD2S1210), increasing system complexity. A resolver is essentially a special transformer whose output signal amplitude varies sinusoidally/cosinusoidally with rotor angle. The absolute angle is obtained by computing these two signal channels.
Mechanical and Calibration-Level Errors Cannot Be Ignored
Before blindly pursuing more expensive encoders, engineers should examine other error sources. Sensor accuracy is often just one link in the error chain.
- Mechanical clearance and backlash: If the joint uses gear transmission, backlash can introduce angular deviations far exceeding encoder error. In a gearbox with a 100:1 reduction ratio, even if the output-side backlash is only 0.1 degrees, if the encoder is mounted on the motor side (input side), that backlash's effect on the end angle is completely invisible, causing severe position errors.
- Link stiffness and deflection: Link bending under load directly affects end-effector position. For a 0.3-meter aluminum alloy link, even a few newtons of end-effector load can produce 0.1-0.5mm deflection.
- Calibration errors: Inaccurate calibration of link lengths and joint zero positions introduces systematic errors. Kinematic Calibration can often significantly improve accuracy without changing hardware.
- Mounting concentricity: Magnetic encoders are extremely sensitive to magnet-chip alignment. Eccentric mounting will dramatically reduce actual accuracy. The AS5048 datasheet explicitly states that 0.5mm of eccentricity introduces additional angular error.
The Practical Value of Kinematic Calibration
Kinematic Calibration is the process of correcting a robot's nominal geometric parameters through actual measurements. The standard procedure includes four steps: modeling (selecting a kinematic model that includes error parameters), measurement (collecting actual pose data of the end-effector at multiple configurations), identification (solving error parameters through optimization algorithms such as least squares), and compensation (writing the identified parameter corrections into the controller). Commonly used measurement equipment includes laser trackers, coordinate measuring machines (CMM), or vision calibration boards. For low-cost scenarios, it's even possible to use calibration points at precisely known positions combined with end-effector contact detection. Research shows that for typical 6-DOF industrial robots, kinematic calibration can improve absolute positioning accuracy from factory ±1-2mm to ±0.1-0.3mm — a significant improvement.
In many practical cases, performing a complete kinematic calibration yields accuracy improvements that even surpass those from replacing sensors with more expensive ones.
Summary of Rotary Encoder Selection Recommendations
For this developer's scenario, the following approach is recommended:
- Start with error source analysis: Use calibration to confirm whether errors originate from sensors, mechanics, or algorithms — avoid blindly upgrading hardware. A simple method is to fix the robotic arm in a certain configuration and repeatedly read encoder values, observing the repeatability of readings (random noise) and deviation from known angles (systematic error), thereby distinguishing the contributions of different error sources.
- If higher-accuracy sensors are truly needed: Consider absolute optical encoders (such as the Broadcom AEAT series) or high-accuracy inductive encoders, with nominal accuracy entering the 0.1-degree range. For budget-limited projects, self-calibration compensation of magnetic encoder INL through multi-revolution sampling is also worth considering.
- Pay attention to installation quality: Even a good sensor will have its performance wasted by poor mounting. Use dedicated encoder mounting fixtures to ensure concentricity and consistent air gaps.
- Algorithm-level compensation: Building lookup tables for known systematic errors and performing software compensation is an effective low-cost method to improve accuracy. The specific approach is to use high-precision reference equipment (such as angle blocks or optical autocollimators) to calibrate the encoder's actual error curve at multiple angular positions, storing compensation values in the controller for real-time correction.
This question from a technical community is actually a classic challenge that all precision electromechanical system developers face — understanding the difference between "resolution" and "accuracy" and systematically analyzing the entire error chain is often more effective at solving problems than simply pursuing expensive components.
Related articles

AI-Powered SRC Vulnerability Hunting: A Hands-On Guide to Building the Hermes Agent Workbench
Based on a hands-on Bilibili video: how to build an AI-powered SRC vulnerability hunting workbench—three-step method, four report elements, Agent mode vs web chat, and tool selection.

CLI-Anything Complete Beginner's Guide: How AI Operates Software — Principles and Practice
A complete beginner's guide to CLI-Anything: how AI Agents operate professional software via the command line, covering the three-layer architecture, CLI Hub installation, DrawIO practice, generator principles, and limits.

Carbon-X: A 14.8B Open-Source Model That Handles DNA and Text Simultaneously
Carbon-X is a 14.8B open-source multimodal model on Hugging Face where DNA and text share a token stream. 6-mer tokenization, 302B token mid-training, deployable on a single 80GB GPU, 66.7% average on five DNA benchmarks, Apache 2.0 license.