Robotic Arms Autonomously Harvesting Mushrooms: Breakthroughs and Challenges in Agricultural Automation

Robotic arms achieve autonomous mushroom harvesting, seeking real-world farm partnerships to bridge the lab-to-field gap.
A research team has developed a robotic arm capable of autonomously identifying and harvesting mushrooms, addressing challenges of soft tissue handling, dense growth patterns, and maturity detection. The team is pursuing open collaboration with growers to collect real-world data for algorithm optimization, tackling the classic sim-to-real gap. With mushroom harvesting labor costs comprising 40-50% of production expenses and growing labor shortages, automated picking represents a high-potential AgTech application.
From Lab to Mushroom House: Robotic Mushroom Picking Becomes Reality
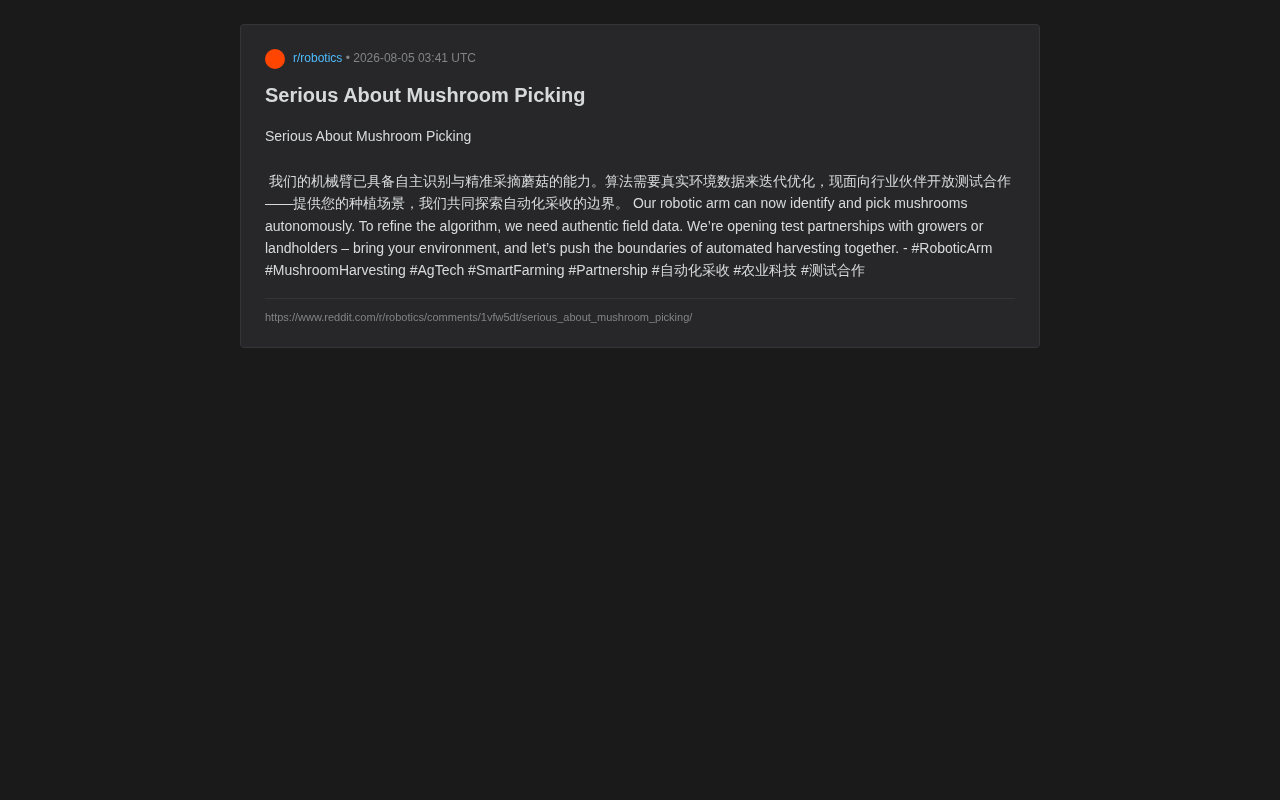
A compelling new application has recently emerged in agricultural automation: a research team has announced that their robotic arm is now capable of autonomously identifying and precisely harvesting mushrooms. This is more than just a technology demonstration — the team is actively opening up testing partnerships with industry players, hoping to continuously iterate their picking algorithms using data from real cultivation environments.
According to information released by the team, they are currently seeking growers or facility partners to validate and optimize system performance in real mushroom house environments. This collaborative stance of "bring your environment, and let's push the boundaries of automated harvesting together" reflects a pain point common across AgTech today — the gap between laboratory results and real-world field conditions.
Why Mushroom Picking Is a Classic Challenge in Robotic Manipulation
The Multiple Challenges of Soft, Fragile, and Densely Growing Produce
Mushroom picking may seem simple, but it's actually one of the classic hard problems in robotic manipulation. Robotic manipulation is a core subfield of robotics, studying how mechanical systems can physically interact with objects in unstructured environments. Unlike assembly robots on industrial production lines that follow fixed trajectories, agricultural manipulation tasks require robots to possess closed-loop perception-decision-execution capabilities — sensing target states in unknown or semi-unknown environments in real time, planning grasping strategies, and executing fine motor actions. The key difficulty in this field is "generalization" — the environment, shape, and position of target objects differ every time, making it impossible for robots to simply repeat pre-programmed motions.
Unlike picking relatively uniform crops such as apples or tomatoes, mushrooms present several particularly tricky characteristics:
- Soft texture, easily damaged: The cap and stem are extremely fragile — even slightly inappropriate gripping force can downgrade product quality, directly impacting commercial value;
- Dense growth with varied orientations: Mushrooms on growing beds often cluster together with minimal spacing between individuals. The robotic arm must precisely locate targets in crowded environments while avoiding damage to adjacent specimens;
- Complex maturity assessment: Harvesting timing is critical to mushroom quality. The system must not only "see" mushrooms but also determine which ones have reached harvest-ready standards.
The Dual Challenge of Visual Recognition and Motion Control
To accomplish automated mushroom harvesting, the robotic arm system must simultaneously solve problems at two levels.
First is computer vision recognition: using deep learning algorithms to accurately detect the position, size, and orientation of each mushroom under complex lighting and background conditions. Deep learning — particularly Convolutional Neural Networks (CNNs) and more recently Transformer architectures — has become the mainstream technical approach for agricultural computer vision. In mushroom detection scenarios, commonly used object detection frameworks such as the YOLO series and Mask R-CNN can achieve instance-level segmentation — not only identifying that mushrooms exist, but precisely delineating the contour boundaries of each individual mushroom. However, the special challenges of agricultural scenarios include: dramatic lighting variations (from natural light to LED supplemental lighting), complex backgrounds (growing substrate colors similar to mushrooms), and severe occlusion (dense growth causing target overlap). These factors mean that models pre-trained on general datasets must be fine-tuned with domain-specific data to achieve usable accuracy.
Second is precision motion control: translating recognition results into precise grasping actions and applying just the right amount of force to complete harvesting without damaging the product. Force control is a key technology for picking soft agricultural products. Traditional industrial robots mostly use position control — simply reaching designated coordinates is sufficient — but mushroom picking requires hybrid force-position control strategies: the robotic arm switches to force control mode when approaching the target, monitoring gripping force in real time through force/torque sensors to ensure a firm grip without crushing the cap. End-effector design is also crucial, with common approaches including vacuum suction cups, soft grippers, and biomimetic finger structures, each with its own advantages and disadvantages across different mushroom varieties and sizes.
This also explains why the team particularly emphasizes the need for "real environment data for iterative optimization" — algorithm performance in standardized laboratory environments often cannot transfer directly to the vastly different conditions of real mushroom houses. This involves a classic problem in machine learning — domain transfer or the Sim-to-Real gap. Many robotics research teams first generate large amounts of training data in simulated environments (low cost, fast speed, high controllability), but simulators cannot perfectly reproduce real-world material reflections, sensor noise, physical contact properties, and other details. This "reality gap" causes strategies that perform excellently in simulation to suffer dramatic performance drops in real deployment. Mainstream methods for bridging this gap include domain randomization, adversarial domain adaptation, and few-shot fine-tuning directly in real environments — the latter being the core motivation behind the team's search for collaborators. Every cultivation scenario's lighting conditions, bed layout, and variety differences becomes a test for the algorithm.
Data-Driven Open Collaboration Model
What's noteworthy is the collaboration strategy this team has adopted. Rather than developing behind closed doors until the product is perfect, they are proactively opening up testing partnerships, inviting growers to provide real-world scenarios. The logic behind this approach is clear:
For automated harvesting systems that rely on machine learning, the diversity and authenticity of training data directly determines model generalization capability. A picking algorithm trained in only a few fixed environments will struggle to handle the various edge cases encountered during commercial deployment. By partnering with real growers, the team can collect valuable data covering different varieties, growth stages, and environmental conditions.
For growers, this is also a low-barrier opportunity to experience cutting-edge agricultural technology. The global mushroom cultivation industry exceeds $50 billion in scale, with labor costs for the harvesting stage typically accounting for 40%-50% of total production costs. Taking European and American markets as examples, mushroom pickers must work bent over in enclosed mushroom houses with high humidity (85%-95%) and constant temperature (14-18°C) — physically demanding conditions that also require considerable skill, as workers must judge each mushroom's maturity by experience and twist-pick with the correct technique. In recent years, tightening immigration policies and workforce aging have exacerbated labor shortages, with some large European mushroom farms reporting seasonal labor gaps exceeding 30%, creating strong market pull for automated harvesting. If automated picking robots can mature and be deployed, they could significantly reduce labor costs while improving harvesting efficiency and product consistency.
Industry Status and Prospects for AgTech Automated Harvesting
The Wave of Picking Robots
Mushroom harvesting robotic arms are not an isolated case. In recent years, agricultural robots have seen extensive R&D investment in automated harvesting of strawberries, tomatoes, peppers, and other crops. The driving forces behind this wave include global agricultural labor aging, continuously rising labor costs, and the spread of precision agriculture concepts.
However, commercial deployment of picking robots consistently faces economic viability challenges. The system's picking speed, success rate, and unit cost must be competitive with manual labor to gain real acceptance from growers. Currently, more advanced strawberry picking robots in the industry achieve 8-12 picks per minute, but success rates generally range from 70%-85%, still falling short of the 95%+ success rate of human workers. The advantage of mushroom picking lies in the relatively controllable mushroom house environment (indoor, constant temperature and humidity, artificial lighting), unlike open-air orchards facing extreme variables such as wind, rain, and sun exposure. This makes it easier to ensure robot system stability, and is why the industry widely considers mushrooms to be the "lowest-hanging fruit" for automated harvesting. Due to their short growth cycles, frequent harvesting needs, and relatively stable yields, mushrooms are theoretically one of the most promising categories for automated harvesting.
The Distance from "Can Do" to "Do Well" in Technology Deployment
A realistic perspective is needed: there remains considerable distance between "the robotic arm is capable of autonomous picking" and "large-scale commercial deployment." Success rates during technology demonstration phases and performance in controlled environments represent an entirely different magnitude compared to all-weather, high-volume, high-reliability production-grade applications. The team's open testing collaboration is essentially bridging this distance — using real-scenario data to polish the system from "can do" to "do well."
From an engineering deployment perspective, production-grade deployment still requires solving a series of non-algorithmic issues including system integration, maintenance accessibility, and compatibility with existing mushroom house infrastructure. The reliability of a robotic arm operating continuously for thousands of hours in a mushroom house, sensor durability in high-humidity environments, and data interoperability with mushroom house management systems — these engineering details often determine commercial success or failure more than the algorithms themselves.
Conclusion: A Pragmatic Step Forward for Agricultural Robotics
This team's approach embodies a pragmatic technology development path: first validating core capabilities on a specific, well-defined task (automated mushroom harvesting), then continuously iterating through open collaboration and real data acquisition, rather than pursuing a one-step universal solution.
For observers tracking the deployment of AI and robotics technology, mushroom harvesting robotic arms are a case worth following — they both showcase the latest advances in robotic manipulation technology for flexible, fragile targets, and reveal the data and engineering thresholds that must be crossed in moving from algorithm prototype to field production. The boundaries of agricultural automation are being pushed forward precisely through such real-world collaborations and iterations, one step at a time.
Related articles

Cursor Can Now Control Your Computer: AI Agents Can Drive Desktop Apps for Testing
Cursor adds desktop control: AI agents can drive desktop apps like the iOS Simulator to test their own features. We analyze the impact on dev workflows, possible technical approaches, and reliability concerns.

Vibecoding a Custom Inference Engine: High Hopes, Harsh Reality
A Reddit developer shares the real experience of vibecoding a custom inference engine: running GGUF Q4 models in the browser with WebGL2 and GLSL, only to fall into tokenizer debugging hell. This article analyzes the engineering challenges of browser-side LLM inference and why cloning llama.cpp is the more rational choice.

How High Are Anthropic's Early Investor Paper Returns Ahead of IPO?
Anthropic's early investor paper returns draw attention ahead of IPO. This article analyzes sources of book gains, capital structure, pre-IPO games and risks, and implications for the AI startup ecosystem.