Building a 4WD SLAM Radar Robot with Arduino R4 WiFi
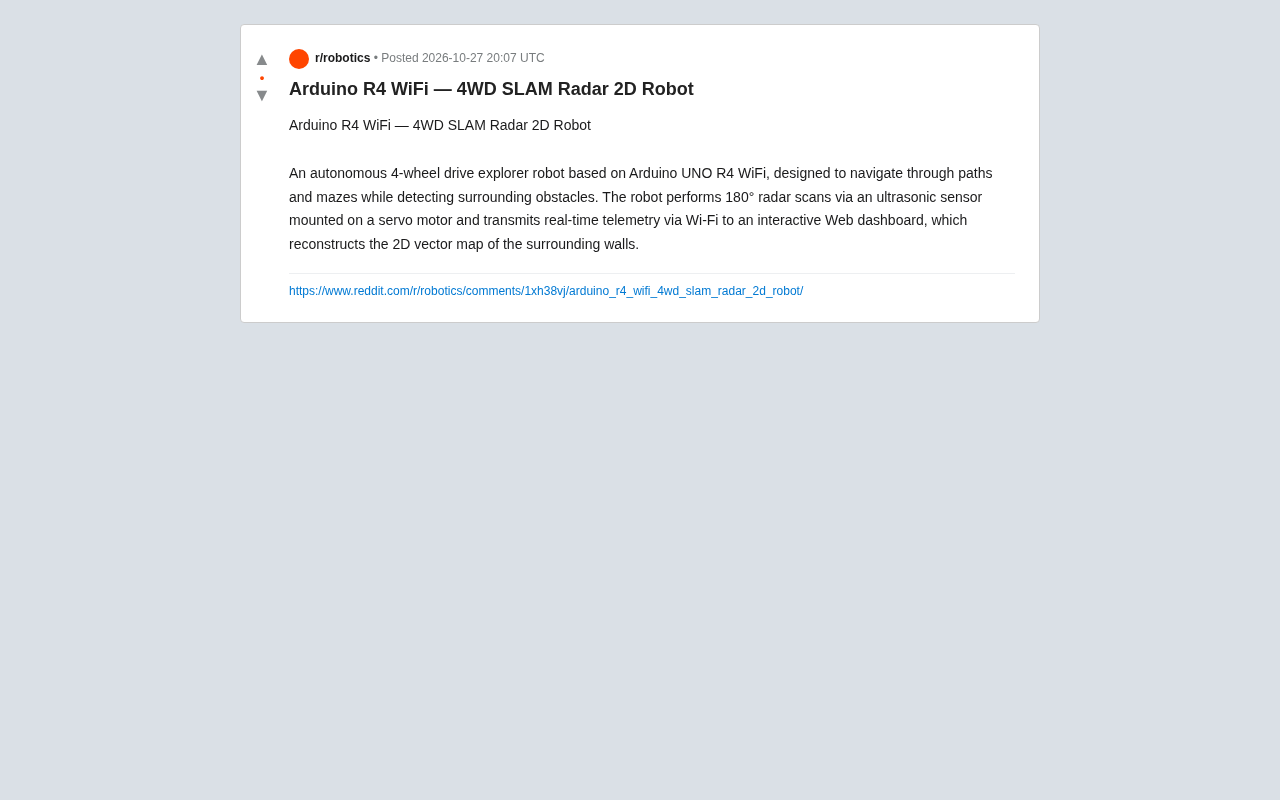
An Arduino UNO R4 WiFi 4WD robot uses servo-based ultrasonic scanning and web mapping for low-cost SLAM入门.
This article introduces a four-wheel-drive exploration robot based on the Arduino UNO R4 WiFi, whose core idea is to complete a SLAM proof of concept with low-cost hardware. The robot uses a servo-mounted ultrasonic sensor for 180° mechanical scanning, collects environmental distance data in polar coordinates, and transmits it in real time via the R4 WiFi's built-in Wi-Fi module to a web dashboard. The browser converts polar coordinates to Cartesian coordinates and reconstructs a 2D vector wall map, shifting the computational load from the microcontroller to the web side. The article analyzes the decoupled hardware architecture and the trade-off between scanning speed and ranging stability, and notes that although the project is not complete SLAM, it connects the full chain from sensor acquisition and wireless transmission to visualization, making it suitable for maker beginners and education.
From the Garage to the Maze: The Birth of a 4WD SLAM Radar Robot
In the maker community, building an obstacle-avoiding car with Arduino is nothing new. But a four-wheel-drive exploration robot based on the Arduino UNO R4 WiFi recently shared on Reddit focuses on "mapping" rather than simply "driving"—it uses a servo-mounted ultrasonic sensor to perform a 180° radar scan and transmits real-time telemetry data over Wi-Fi to an interactive web dashboard, which reconstructs a 2D vector map of the surrounding walls. This project brings the entry threshold of SLAM (Simultaneous Localization and Mapping) down to a level accessible to hobbyists.
How the Hardware Is Built: R4 WiFi Is a Suitable Base
The core of this robot is the Arduino UNO R4 WiFi. Compared with previous generations, the R4 WiFi has built-in Wi-Fi and Bluetooth modules, eliminating the need for an external ESP8266/ESP32 and making the real-time telemetry link clean. The four-wheel-drive chassis handles movement along paths and through mazes, while the ultrasonic sensor is mounted on a servo and achieves 180° scanning through servo rotation—a typical "single-point ranging + mechanical scanning" approach that is low-cost but effective.
The source code description does not reveal the motor model, battery specifications, or specific sensor model, but the architecture is clear: the chassis handles motion, the servo + ultrasonic sensor handles perception, and the R4 WiFi handles communication. The three modules have clear divisions of labor, so a problem in any one module will not cripple the entire system. For hobbyists who want to get started with robot perception, this decoupled design is worth learning from.
Key Features of the Arduino UNO R4 WiFi: The R4 WiFi is a new-generation product in the Arduino UNO series. Its main controller is the Renesas RA4M1 (32-bit Cortex-M4), and it integrates an ESP32-S3 module to provide Wi-Fi and Bluetooth connectivity. Compared with the classic UNO, it adds peripherals such as CAN bus, a 12-bit DAC, and an operational amplifier. Its GPIO voltage remains 5V, making it compatible with most traditional expansion boards. Built-in Wi-Fi means it can connect directly to the network without an external ESP8266, which significantly simplifies wiring and power supply design for telemetry projects—an important reason this project chose it as the base.
180° Radar Scanning: Trading Mechanical Rotation for Field of View
An ultrasonic sensor can only measure distance in one direction. Once mounted on a servo, by programming the servo to sweep from left to right across 180°, a set of distance data in polar coordinates can be obtained. Although the scanning speed and angular resolution cannot compare with LiDAR, it is sufficient for tasks such as maze navigation and wall contour reconstruction.
Interestingly, the data update rate of this approach is limited by the servo's rotation speed. The faster the scan, the shorter the dwell time at each angle, and the worse the ranging stability; the slower the scan, the more obvious the mapping delay. This is a trade-off that needs repeated tuning in practice, and it is also the most engineering-flavored part of the project.
Conversion Between Polar and Cartesian Coordinates: As the ultrasonic sensor sweeps 180° under servo control, each angle θ corresponds to a distance r, and this set of (θ, r) is the polar coordinate representation. When drawing the map on the web side, it must be converted to Cartesian coordinates: x = r·cos(θ), y = r·sin(θ). Understanding this is key to understanding the mapping logic. Because both the servo angle and the ultrasonic ranging have errors, the converted points will contain noise. In actual projects, it is often necessary to take the median of multiple measurements at the same angle or smooth adjacent points to obtain a relatively clean wall contour.
Wi-Fi Telemetry and Web Dashboard: Moving Mapping into the Browser
Another highlight of the robot is that it transmits data in real time to a web dashboard. After the R4 WiFi connects to the network, it sends out the distance data corresponding to each scanning angle. Once the browser receives it, it converts these polar coordinate points into Cartesian coordinates and then draws them into a 2D vector map.
The advantage of this architecture is that the computational load is shifted to the more powerful web side, while the microcontroller only needs to handle acquisition and transmission. The dashboard serves both monitoring and visualization roles, allowing you to intuitively see the world "through the robot's eyes" during debugging. For educational scenarios or project demonstrations, this is far friendlier than printing data over serial.
What This Project Reveals: SLAM Doesn't Have to Start with LiDAR
In the professional robotics field, SLAM is almost bound to LiDAR. This robot offers a reverse approach: using the cheapest ultrasonic sensor plus mechanical scanning, together with web-side mapping, it can likewise achieve a "perception-mapping" loop. Of course, its accuracy and robustness cannot be compared, but it pushes the cost of proof of concept to an extremely low level.
For makers, the value of such projects lies not in performance metrics but in connecting the complete chain from sensor acquisition and wireless transmission to visualization. For further upgrades, you could consider adding encoders for odometry, fusing IMU data, or switching to a multi-sensor layout to reduce scanning blind spots—all of which are directions that can naturally extend the existing architecture.
The Basic Loop of SLAM: SLAM (Simultaneous Localization and Mapping) contains two interdependent tasks—localization (estimating the robot's own pose in the map) and mapping (updating the environment map based on observations). This project mainly completes the mapping part: assuming the robot's position is known or fixed, it directly stitches the scan points into a map. Strictly speaking, SLAM also requires odometry or an IMU to provide pose changes so that multiple scans can be aligned in the same coordinate system. Therefore, it is more accurately "mapping" rather than complete SLAM, but as a proof of concept, it already demonstrates the core chain of perception-transmission-visualization.
Key Takeaways
- A four-wheel-drive exploration robot based on the Arduino UNO R4 WiFi, using built-in Wi-Fi for telemetry.
- A servo-mounted ultrasonic sensor performs 180° scanning and collects environmental distance data in polar coordinates.
- The web dashboard receives the data and reconstructs a 2D vector wall map, with the computational load shifted to the browser.
- The project proves that a low-cost ultrasonic solution can also complete a SLAM proof of concept, making it suitable for beginners and education.
Related articles
One Year of Dioxus Fullstack in Production: Gains and Pain Points
A developer shares a year of real-world experience running the Dioxus fullstack framework in production, covering type-safety gains in fullstack Rust, plus pain points like compile times and ecosystem maturity, as a reference for technology selection.
The Hidden Faith of AGI Leaders: Humans Are Nothing Special?
Vergecast podcast reveals the hidden belief within AGI leadership circles: humans are nothing special, consciousness is just computation. Exploring how computational functionalism shapes the worldview of tech elites and the future of AI.
GM Shifts Toward Hybrids: From an All-Electric Bet to a Pragmatic Parallel Strategy
GM once skipped hybrids to bet on pure EVs; now it plans hybrid SUV versions. This article analyzes the strategic shift, its significance for SUVs, and consumer impact.