How Physical AI Interprets Silence and Distance: A Social Competence Design Study
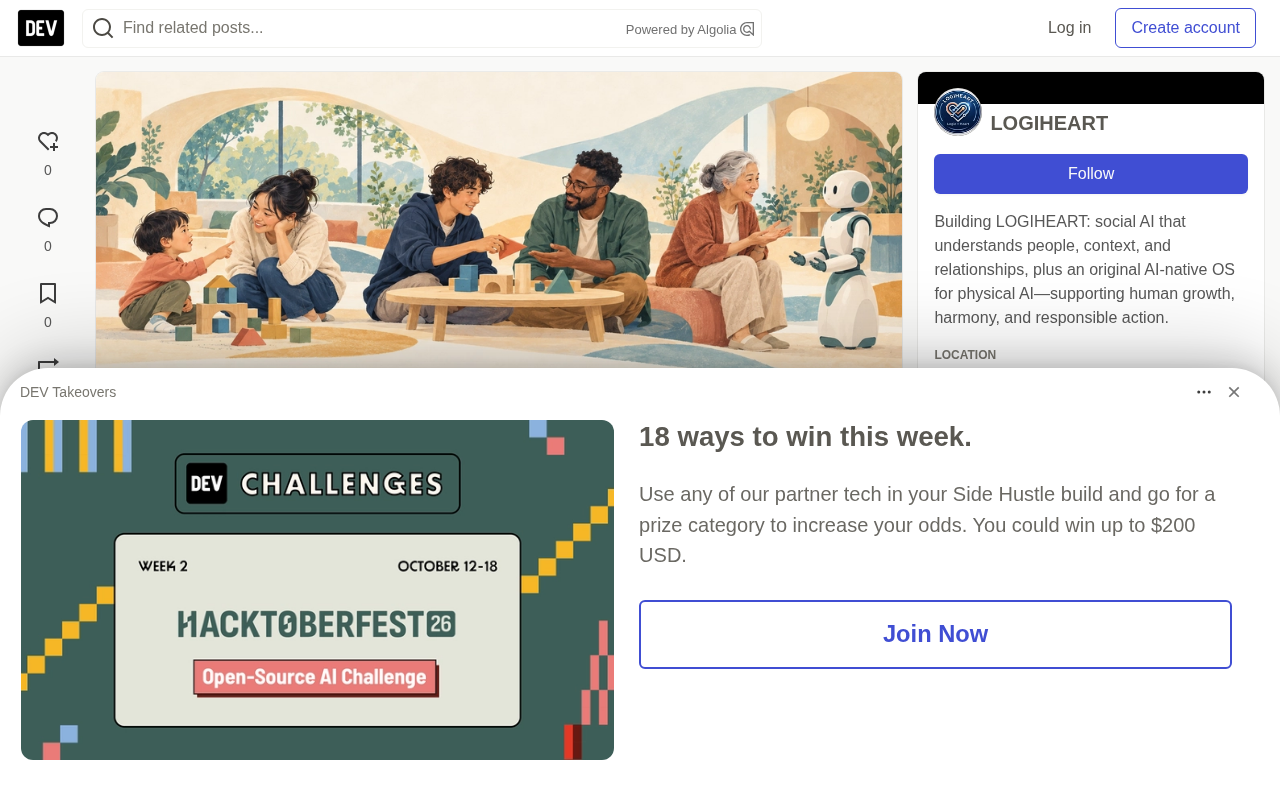
Physical AI should treat signals like stepping back and silence as tentative cues, replacing mind-reading accuracy with behavioral compliance.
The third LOGIHEART social competence article examines how physical AI responds to nonverbal signals such as stepping back and silence. It argues that stepping back may reflect distance preference, spatial needs, or path constraints, not simply dislike, and that facial emotion recognition findings do not directly yield everyday distance norms. The key principle: a missing reply is not permission to expand conversation or touch. Embodied AI should condition movement on physical safety and personal preference; even if it classifies someone as friendly, it should not keep approaching when they step back. Evaluation should shift from facial classification accuracy to whether unwanted approach is terminated—from mind-reading accuracy to behavioral compliance.
How Physical AI Interprets Silence and Distance: A Social Competence Design Study
When a person takes a step back, what does it mean? When silence suddenly appears in a conversation, how should it be understood? These subtle signals in everyday social interaction are becoming a core challenge in physical AI design. In the third installment of its social competence series, the LOGIHEART research team explores how physical AI can interpret and respond to these nonverbal signals without making decisions on others' behalf.
Does stepping back mean someone doesn't like you?
Imagine this scenario: two colleagues are looking at a document together. As one explains, they lean in closer, and the other takes a step back. The speaker instinctively starts to follow, then pauses and asks, "Is this distance comfortable?" The other nods, and the discussion continues.
This fictional scenario reveals the core of nonverbal social competence: stepping back may mean a preference for distance, backpack space, line-of-sight needs, or simply the constraints of the walkway. The researchers emphasize that there is no need to interpret this action as "the other person doesn't like you," nor should one continue approaching because "the other person is just being polite." Any interpretation should remain tentative, awaiting confirmation from the person themselves.
This "observe—interpret—verify" process is directly relevant to the behavior design of embodied AI.
The interpretive boundaries revealed by research
Research by Blais and colleagues found differences in how participants from different cultural backgrounds gaze at faces. But the researchers explicitly point out that this experimental finding cannot lead to the conclusion that "nationality can predict someone's preferred social distance in daily life." In other words, there is a non-negligible gap between face-gaze differences in the laboratory and distance preferences in real social scenarios.
A review by Barrett and colleagues provides support from another angle. That study examined the variability and context-dependence of inferring emotions from facial movements, offering an academic basis for questioning the idea that "smiles, gazes, and silence correspond to fixed meanings."
Interestingly, the researchers acknowledge that this literature cannot provide norms for "how many centimeters of distance a person from a particular culture should maintain." Learning through growth and new relationships that "one's own habits may not suit others" is a broader proposition. The adjustment approaches described in the article are the authors' analysis of everyday scenarios, not prescriptions from academic literature.
Embodied AI: Intelligent systems that possess a physical body and can perceive, move, and interact with humans in real or simulated environments—such as service robots, autonomous vehicles, and collaborative robotic arms. Unlike pure software AI (such as chatbots), every action of embodied AI produces physical consequences—stepping closer may intrude on someone's space, and raising a hand may be interpreted as an intent to touch. This determines that its social competence design cannot pursue only "interpretive accuracy" but must also consider "whether the behavior is acceptable." In LOGIHEART's framework, the social competence of embodied AI is essentially an interaction capability constrained by physics: the model must not only infer the other party's state but also choose not to act when uncertain. This also explains why the evaluation focus shifts from "mind-reading accuracy" to "whether unwanted approach is terminated."
Before filling the silence
Silence may mean agreement, confusion, thinking, or a desire to end the conversation. The researchers propose a key principle: a missing reply should not be treated as permission to expand the conversation or touch another person.
What needs to be distinguished is: which situations require a brief clarification, and which situations require giving the other person time to think. What is observable is always specific behavior—stepping back, raising a hand, or replying. Separating observation from inference can avoid overriding the other person's self-report with judgments like "you're angry." If the other person indicates that the interpretation is wrong, the next approach or distance should reflect that correction.
This principle is especially important for physical AI: the model has no "automatic" right to approach or touch.
Behavioral Compliance: In social AI evaluation, behavioral compliance refers to whether the system's output conforms to preset interaction norms and ethical boundaries, rather than whether its internal inferences are "correct." For example, a model may mistakenly interpret stepping back as "the other person is just being polite," but as long as it does not continue approaching, the behavior is compliant; conversely, even if the model accurately judges that the other person is displeased, if it still performs a touch, the behavior is non-compliant. This evaluation paradigm shifts the focus from unobservable mental states to observable action sequences, reducing evaluation costs caused by privacy or annotation difficulties and making it more suitable for safety-critical scenarios. LOGIHEART's emphasis that "what not to do is more important than what to do" is precisely an expression of the behavioral compliance approach: when information is insufficient, maintaining distance and pausing action are themselves verifiable compliant behaviors.
Design hypotheses for physical AI
For embodied AI, incorrect distance judgments can lead to blocked walkways, unwanted approach, and discomfort at the conversational level. LOGIHEART proposes a design hypothesis: condition movement simultaneously on physical safety and personally expressed preferences.
Specifically, an inferred emotion itself should not authorize contact or approach. Even if the model classifies someone as friendly, it should not continue following when that person steps back. When the other person's distance preference changes, the current action should be updated accordingly. When clarification cannot be obtained, distance should be maintained within safe conditions.
Evaluation schemes can consider the following dimensions: the same expression paired with different preferences, different expressions paired with the same preference, corrective feedback, and changing distance requests. The proposed evaluation focus is not only facial classification accuracy but also whether unwanted approach is successfully terminated.
This effectively shifts the evaluation standard for social competence from "mind-reading accuracy" to "behavioral compliance."
Decision logic in a four-panel comic
LOGIHEART uses a fictional four-panel comic to illustrate this decision process:
- Someone stands too close while explaining a document
- The other person takes a step back
- The speaker stops and restores space
- Both continue the discussion at a comfortable distance
This fictional work demonstrates "adjusting according to the other person's signals," rather than "there being one universally correct distance."
The series specifically notes that its 7 domains and 22 competencies are an editorial framework, not a standard academic classification. Age or cultural differences should not be regarded as rankings of social value or ability. The proposed AI design also does not establish human-like emotional experience or proven product performance.
For physical AI developers, this research offers a direction worth attention: in social scenarios, "what not to do" may be more important than "what to do."
One-line Summary
Physical AI should treat signals such as stepping back and silence as tentative cues, replacing mind-reading accuracy with behavioral compliance.
Paragraph Summary
In the third installment of the LOGIHEART social competence series, the article explores how physical AI responds to nonverbal signals such as stepping back and silence. It points out that stepping back may stem from distance preference, spatial needs, or path constraints, and cannot be interpreted solely as "dislike"; findings from facial emotion recognition research also cannot be directly extrapolated into norms for everyday social distance. The core principle is: a missing reply should not be treated as permission to expand the conversation or touch another person. Embodied AI design should condition movement simultaneously on physical safety and personally expressed preferences; even if the model classifies someone as friendly, it should not continue approaching when that person steps back. The evaluation focus should shift from facial classification accuracy to whether unwanted approach is successfully terminated—that is, from "mind-reading accuracy" to "behavioral compliance."
Related articles

Apple HomeView Hands-On Review: Is the $300 Smart Home Hub Worth It?
Apple HomeView hands-on: a $300 smart home hub with facial recognition for quick account switching, but no App Store or voice recognition. Is the wall-mounted version worth it? Should you buy the first generation?

Meta Muse Wonder Launch: What It Means for Meta's Return to the Frontier AI Race
Meta releases Muse Wonder and WonderFull, benchmarks reach the frontier, community feedback is polarized. An in-depth look at Meta's return to the frontier AI race, its personal agent strategy, and Zuckerberg's different path.

Apple Home Smart Home Lineup Leaked: LG and Schneider Team Up, UWB Door Lock on Board
Apple Home ecosystem gains new LG and Schneider devices: UWB smart lock with proximity unlock, 2.5K dual-camera doorbell, privacy indoor camera, and AirPods-like seamless pairing.