Open-Source Autonomous Driving Model Alpamayo 2 Edge Released: Edge Inference Speeds Up Over 10x
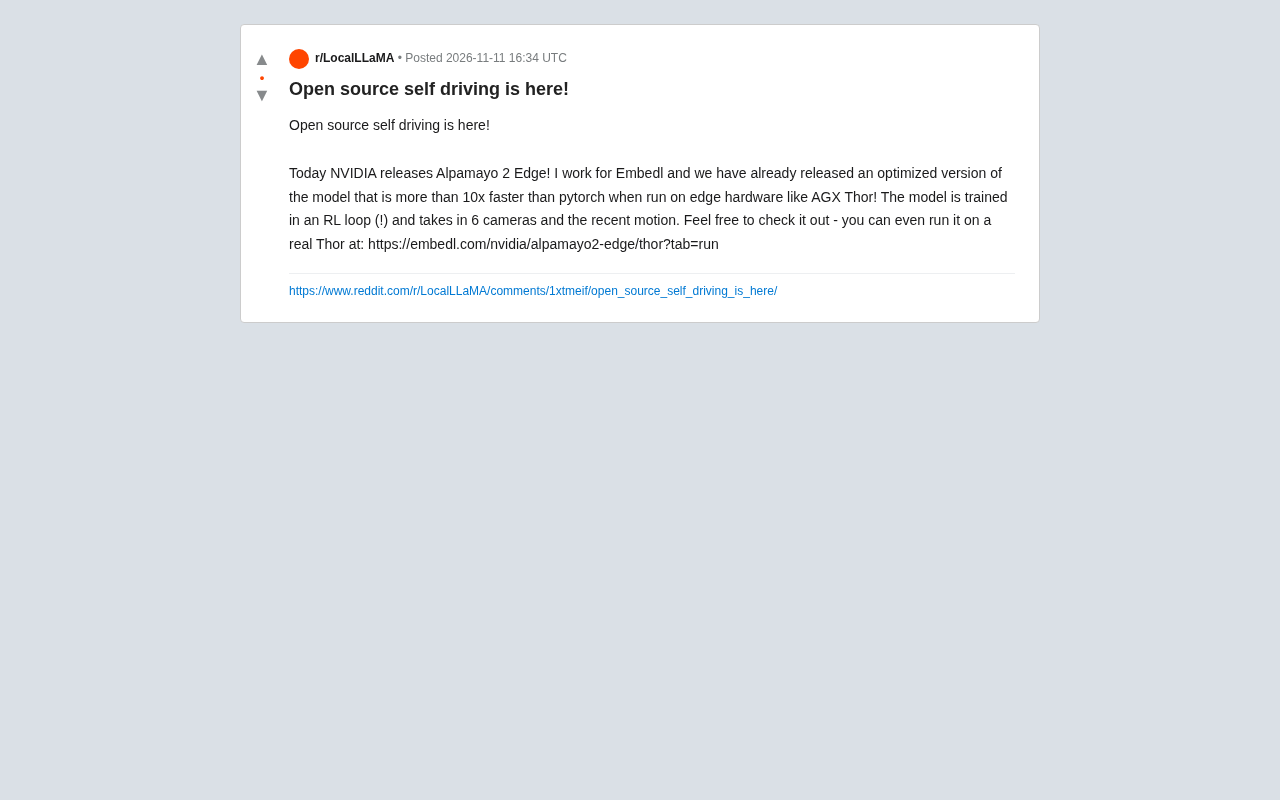
NVIDIA open-sources the autonomous driving model Alpamayo 2 Edge, with Embedl's optimized version achieving over 10x speedup on edge hardware.
NVIDIA released the open-source autonomous driving model Alpamayo 2 Edge, trained with a reinforcement learning loop, taking input from 6 camera feeds and vehicle motion information, and designed for edge computing. Edge AI optimization company Embedl simultaneously launched an optimized version that runs over 10x faster than the PyTorch implementation on edge hardware such as AGX Thor, and provides an online portal where developers can run the model directly on real Thor hardware. The article analyzes the impact on the open-source autonomous driving landscape: complete end-to-end driving models with edge deployment capability were previously rare, and this release forms a full chain from model to deployment, valuable for both research and engineering. It also notes that edge deployment still faces challenges such as power, heat, and memory bandwidth, and that current information mainly comes from one-sided Reddit disclosure pending official documentation and community verification.
NVIDIA today released the Alpamayo 2 Edge model, dropping a bombshell on the open-source autonomous driving space. Even more notable is that edge AI optimization company Embedl simultaneously launched an optimized version of the model, achieving inference speeds over 10x faster than the PyTorch implementation on edge hardware such as AGX Thor. This progress means developers are one big step closer to running end-to-end autonomous driving models on real in-vehicle hardware.
What Is Alpamayo 2 Edge?
According to information disclosed in the original Reddit post, Alpamayo 2 Edge is an autonomous driving model introduced by NVIDIA. It has three core characteristics: it is trained using a reinforcement learning loop (RL loop), it takes input from 6 camera feeds plus recent vehicle motion information, and it is designed for edge computing scenarios.
Reinforcement learning loop training means the model does not rely solely on imitation learning but continuously optimizes its decision policy through interaction with the environment. The multi-view input from 6 cameras forms a three-dimensional perception of the surrounding environment, and combined with motion information, the model can better understand the dynamic state of the ego vehicle. This configuration aligns with the mainstream end-to-end autonomous driving architecture approach, but making it open source and edge-deployable is the key differentiator of this release.
Reinforcement learning loop (RL loop) refers to an iterative process during model training in which an agent repeatedly executes actions, receives reward signals, and updates its policy in a simulated or real environment. Unlike traditional imitation learning (directly fitting human driving data), an RL loop lets the model optimize long-term returns through trial and error—for example, following vehicles more safely or changing lanes more smoothly. In autonomous driving, RL can mitigate the distribution shift problem in imitation learning—that is, the model tends to fail when it encounters scenarios not covered by the training data. However, RL training usually requires high-fidelity simulation environments and a large number of interaction samples, resulting in high computational cost, which is also one of the barriers to training end-to-end driving models.
AGX Thor is an automotive-grade edge computing platform launched by NVIDIA, belonging to the high-end product line of the Jetson series and designed specifically for autonomous driving and robotics scenarios. It integrates an Arm CPU and an NVIDIA GPU, supports high-bandwidth memory and various in-vehicle interfaces, and delivers compute power at the level of hundreds of TOPS. Unlike data center GPUs, AGX Thor must maintain stable inference under limited power and thermal conditions, so models must undergo optimizations such as quantization and operator fusion to fully leverage its performance. Embedl's 10x speedup is precisely an engineering achievement obtained under these constraints.
Where Does the 10x Speedup Come From?
Embedl's contribution lies in engineering optimization. According to the poster (an Embedl employee), they performed targeted optimization on Alpamayo 2 Edge, enabling it to run over 10x faster than the PyTorch version on edge hardware such as AGX Thor.
This speedup is crucial for autonomous driving. The inference latency of end-to-end models directly affects the vehicle's reaction time, and real-time performance on edge hardware has always been a deployment bottleneck. The 10x speedup is not just a change in benchmark numbers; it is a threshold crossing that takes the model from "able to run" to "usable." Embedl provides an online experience portal, and developers can even run the model on real Thor hardware, which facilitates verification and reproduction.
The Competitive Landscape of Open-Source Autonomous Driving
Open-source autonomous driving is not a new topic, but most previous open-source solutions focused on perception modules or simulation environments, and open-source projects featuring a complete end-to-end driving model with edge deployment capability were rare. The emergence of Alpamayo 2 Edge, combined with Embedl's optimized version, forms a complete chain from model to deployment.
The impact on the industry is reflected at two levels: researchers can conduct secondary development and algorithm validation based on the open-source model, lowering the research barrier; engineering teams can directly evaluate the model's performance on target hardware, shortening the cycle from prototype to product. The Reddit community responded positively, and the poster directly invited developers to try it on the Embedl website. This open attitude helps quickly accumulate community feedback.
Challenges and Opportunities of Edge Deployment
Deploying autonomous driving models to edge hardware poses challenges beyond compute power. Power consumption, heat dissipation, memory bandwidth, and real-time guarantees are all constraining factors. As NVIDIA's hardware platform for edge AI, AGX Thor provides the compute foundation, but whether the model can efficiently utilize these resources depends on the degree of optimization.
Embedl's optimized version demonstrates the feasibility of model compression and inference acceleration technologies in autonomous driving scenarios. A speedup of more than 10x means that models that originally could not meet real-time requirements may be able to achieve usable frame rates on the same hardware. This provides a reference path for more open-source models to move toward edge deployment.
How Developers Can Get Involved
For developers who want to try it, Embedl provides an online experience portal where Alpamayo 2 Edge can be run directly on real Thor hardware. This means you can evaluate the model's inference performance and output results without needing your own hardware.
Interested developers can visit the corresponding page on the Embedl website to view run instructions and details. Building the open-source autonomous driving ecosystem requires more developers to participate in testing, feedback, and contributions, and this release provides a low-barrier entry point.
One note: the current information mainly comes from one-sided disclosure by the Reddit poster. Specific architectural details of the model, training data scale, performance evaluation benchmarks, and more still await official technical documentation and community verification. The true maturity of open-source autonomous driving still requires time and practical validation.
One-line Summary
NVIDIA open-sources the autonomous driving model Alpamayo 2 Edge, with Embedl's optimized version achieving over 10x speedup on edge hardware.
Paragraph Summary
NVIDIA released the open-source autonomous driving model Alpamayo 2 Edge, trained with a reinforcement learning loop, taking input from 6 camera feeds and vehicle motion information, and designed for edge computing scenarios. Edge AI optimization company Embedl simultaneously launched an optimized version that achieves inference speeds over 10x faster than the PyTorch implementation on edge hardware such as AGX Thor, and provides an online experience portal where developers can run the model directly on real Thor hardware. The article analyzes the impact of this progress on the competitive landscape of open-source autonomous driving: open-source projects featuring a complete end-to-end driving model with edge deployment capability were previously rare, and this release forms a complete chain from model to deployment, valuable for both research and engineering deployment. It also points out that edge deployment still faces challenges such as power consumption, heat dissipation, and memory bandwidth, and that the current information mainly comes from one-sided Reddit disclosure and awaits official documentation and community verification.
Related articles
Claude Code in Practice: Filling in Tests with Boundary Cases, Coverage, and Assertions
A practical guide to using Claude Code for unit tests: generating boundary cases with global context, locating uncovered branches to boost coverage, and writing effective assertions. Compares Cursor and Trae.
Test Report in Three Minutes? Lemon Test Report Skill Hands-On: No Fabrication, Fully Auditable
A Bilibili creator shares Lemon Test Report Skill: an AI reporting tool for testers with three modes—test summary, regression verification, and release acceptance. It flags missing data as 'to be confirmed,' catches manual data conflicts on the spot, and outputs an editable draft, a web report, and a verification data package.
Giving a Toilet an IP Address with a Raspberry Pi: An Absurd Yet Hardcore IT Experiment
An IT blogger assigned an IP address to his toilet using a Raspberry Pi and float switch, monitoring flushes via GPIO and correlating with network disconnection logs. This article breaks down the hardware wiring, pull-up resistor principles, 0.1-second polling logic, and installation process, extending to similar approaches in AI Agent security monitoring.