Quadruped Robot Cubic Doggo Load Test: Walking with a 1kg Payload
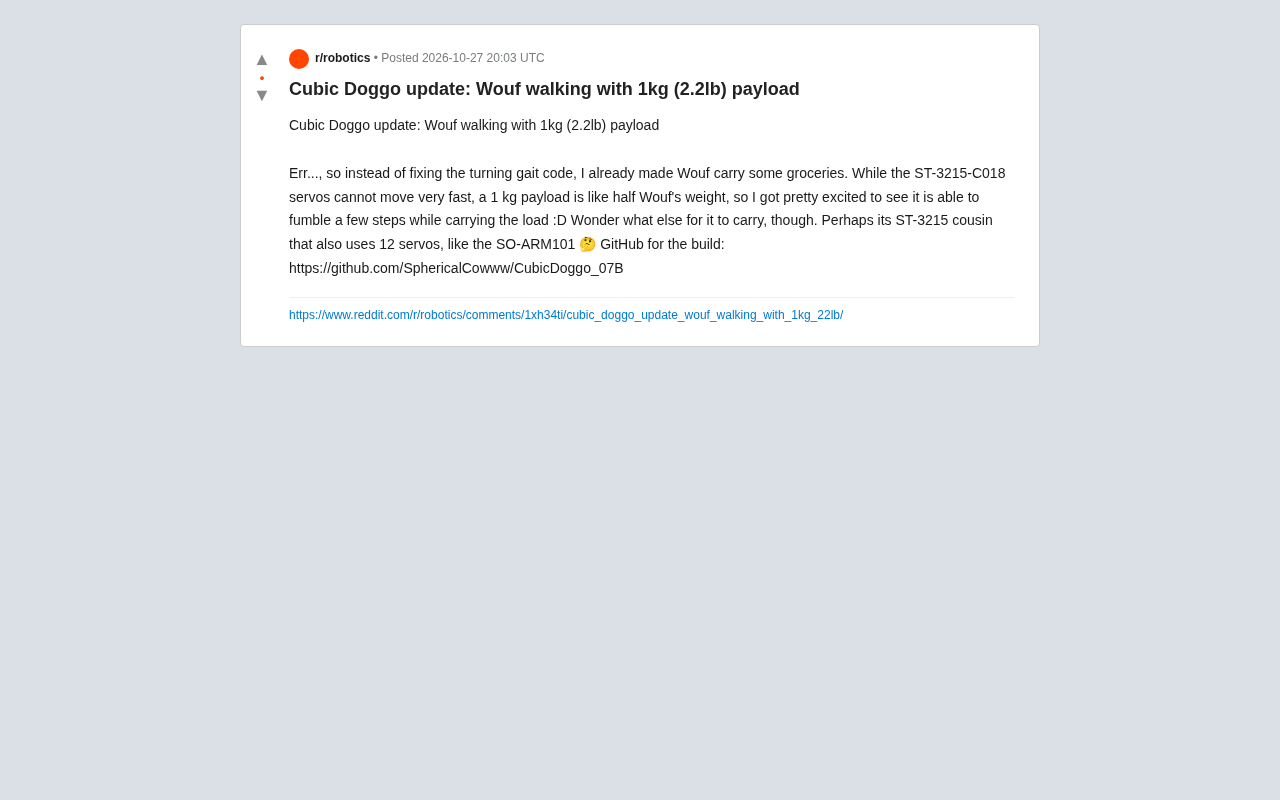
Open-source quadruped robot Wouf walks with a 1kg payload, testing the limits of its servo setup.
A Reddit developer shared the latest progress on the open-source project Cubic Doggo: the quadruped robot Wouf successfully carried 1kg of cargo (about half its own weight) and took a few steps. The project uses 12 ST-3215-C018 servos; the author admits that limited servo speed causes a staggering gait under load, but this precisely verifies the performance boundary of a cheap servo solution under extreme load. The project is open-sourced on GitHub (repository CubicDoggo_07B), and the author also envisions Wouf carrying the SO-ARM101 robotic arm, which shares the same 12-servo platform, hinting at hardware interoperability in the desktop robotics ecosystem. The value of such projects lies in bringing the threshold of quadruped motion control down to a level individual developers can reach.
The quadruped robot hobbyist community has another interesting update. A developer on Reddit shared the latest progress on their open-source project Cubic Doggo: the quadruped robot named Wouf successfully carried 1 kilogram (2.2 lbs) of cargo and took a few steps. Although the gait is still a bit unstable, for a desktop-level project driven by servos, this achievement is enough to excite the author.
A leap from "fixing steering" to "carrying cargo"
The author admits in the post that they should have fixed the steering gait code first, but couldn't resist letting Wouf try carrying groceries first. This "let's play first and figure it out later" developer mentality is quite common in the maker community. What's truly surprising is the result: Wouf actually managed to stagger a few steps while under load.
What does 1 kilogram mean? The author points out that this is roughly half of Wouf's own weight. For a quadruped robot driven by ST-3215-C018 servos, being able to carry 50% of its own weight while maintaining movement shows that its structural design and servo selection have a certain margin of capability.
Power bottleneck: servo speed limits the gait
The author explicitly mentions that the ST-3215-C018 servos cannot move too fast. This explains why Wouf can only "stagger" a few steps rather than walk smoothly. The servo's output speed directly determines the upper limit of the robot's step frequency; under load, the joints need to output greater torque, and the speed is further slowed down.
This also exposes a typical engineering trade-off: building a quadruped robot with cheap servos keeps costs manageable and is easy to get started with, but dynamic performance and load capacity are inevitably limited. Wouf's test is essentially verifying the performance boundary of this servo solution under extreme load.
The relationship between servos and quadruped robot motion
A servo is an actuator that integrates a motor, a reduction gear set, and a position feedback control circuit. A target angle is given via a PWM signal, and internal closed-loop control rotates it to the specified position. Each leg of a quadruped robot typically has 2-3 degrees of freedom, and 12 servos is a common quadruped configuration (3 per leg). Key servo parameters include torque (determines how much weight it can carry), speed (determines the upper limit of step frequency), and precision (determines gait smoothness). Digital servos like the ST-3215-C018 are popular in desktop-level projects because of their low price and simple interface, but their speed is usually measured in "seconds per 60 degrees"; under load, the actual angular velocity decreases due to increased load, causing longer gait cycles and making dynamic balance harder to maintain. This is why Wouf can only stagger when carrying a load rather than walk smoothly.
The difference between dynamic and static gaits
Quadruped robot gaits can be divided into static gaits and dynamic gaits. Static gaits (such as crawl gait) keep at least three legs on the ground at any moment, with the center of gravity projection always falling within the support triangle—good stability but slow speed, with low requirements on actuator speed. Dynamic gaits (such as trot and bound) allow only two legs on the ground at the same time, relying on inertia to maintain balance—fast speed but high requirements on servo response speed and controller real-time performance. The "staggering" phenomenon Wouf exhibits under load is essentially that even a static gait struggles to maintain center-of-gravity stability under load, indicating that its servo speed is insufficient to quickly adjust foot placement, so it can only slow down the pace to barely maintain itself.
Open-source hardware and community collaboration
The project is open-sourced on GitHub under the repository name CubicDoggo_07B. The author chose a somewhat self-deprecating username, "SphericalCowww," which will probably make anyone familiar with physics jokes smile. Open source means other enthusiasts can reproduce this design, or improve the gait algorithm and swap in stronger actuators on top of it.
It's worth noting that at the end of the post, the author proposes an interesting idea: perhaps Wouf could carry its "ST-3215 cousin"—the SO-ARM101 robotic arm, which also uses 12 servos. This idea hints that the desktop-level robotics ecosystem is developing some kind of hardware-level interoperability: similar servo platforms and similar control logic make it possible to combine robots of different forms.
Open-source hardware projects and the GitHub collaboration model
Open-source hardware projects typically publish mechanical structure design files (such as STL, STEP), circuit schematics, firmware code, and assembly instructions together, allowing others to reproduce, modify, and distribute them. As a code hosting platform, GitHub supports developer collaboration through mechanisms such as repositories, issues, and pull requests. The CubicDoggo_07B repository likely contains servo control firmware, gait generation algorithms, and 3D-printed structure files. This model lowers the barrier to entry and also allows gait algorithm iterations to be accelerated with community support. For desktop-level robots, open source also means transparent hardware selection, allowing enthusiasts to swap servos or structural parts according to their budget, enabling differentiated improvements.
The significance of desktop-level quadruped robots
The value of projects like Cubic Doggo lies not in benchmarking against industrial-grade quadruped robots, but in bringing the threshold of quadruped motion control down to a level individual developers can reach. From gait debugging to load testing, every step is real, tangible engineering practice.
The image of Wouf staggering forward with 1 kilogram of cargo may not be elegant, but it records a key step for an open-source project from being able to walk to being usable. Whether the author will go back to fix the steering code or continue adding more weight to Wouf is worth watching.
(This article is based on the original Reddit post and GitHub project information, and does not involve undisclosed technical parameters.)
Related articles
One Year of Dioxus Fullstack in Production: Gains and Pain Points
A developer shares a year of real-world experience running the Dioxus fullstack framework in production, covering type-safety gains in fullstack Rust, plus pain points like compile times and ecosystem maturity, as a reference for technology selection.
The Hidden Faith of AGI Leaders: Humans Are Nothing Special?
Vergecast podcast reveals the hidden belief within AGI leadership circles: humans are nothing special, consciousness is just computation. Exploring how computational functionalism shapes the worldview of tech elites and the future of AI.
GM Shifts Toward Hybrids: From an All-Electric Bet to a Pragmatic Parallel Strategy
GM once skipped hybrids to bet on pure EVs; now it plans hybrid SUV versions. This article analyzes the strategic shift, its significance for SUVs, and consumer impact.