Show HN: AI Agent Infers Mechanisms from Lego Instructions and Animates Them

An early attempt at having AI agents infer mechanical mechanisms from Lego sources and generate animations.
This article introduces a project on Hacker News Show HN titled "Agents infer Lego mechanisms from sources, then animate them." The project has AI agents identify parts and connection relationships from Lego instructions, diagrams, and other raw materials, infer mechanical mechanisms composed of gears and linkages, and then generate animated demonstrations faithful to motion constraints. The article analyzes the key thresholds from static sources to dynamic mechanism reasoning, including spatial reasoning and causal chain establishment, and points out that animations must remain mechanically self-consistent to have practical value. The project received only 13 points and zero comments on the site, with technical details undisclosed, but the direction it represents — "agents + mechanical reasoning + dynamic visualization" — has potential inspirational significance for Lego education, mechanical principles teaching, and rapid validation of mechanism designs.
When AI Agents Learn to "Read" Lego Mechanical Structures
In the Show HN section of Hacker News, a project titled "Agents infer Lego mechanisms from sources, then animate them" has appeared. The title plainly summarizes its capability: an agent infers Lego mechanical mechanisms from raw materials and then converts them into animations. Although the post has received only 13 points (Points: 13 | Comments: 0) on the site, with relatively little discussion, it touches on an interesting direction at the intersection of AI mechanical reasoning and dynamic visualization.
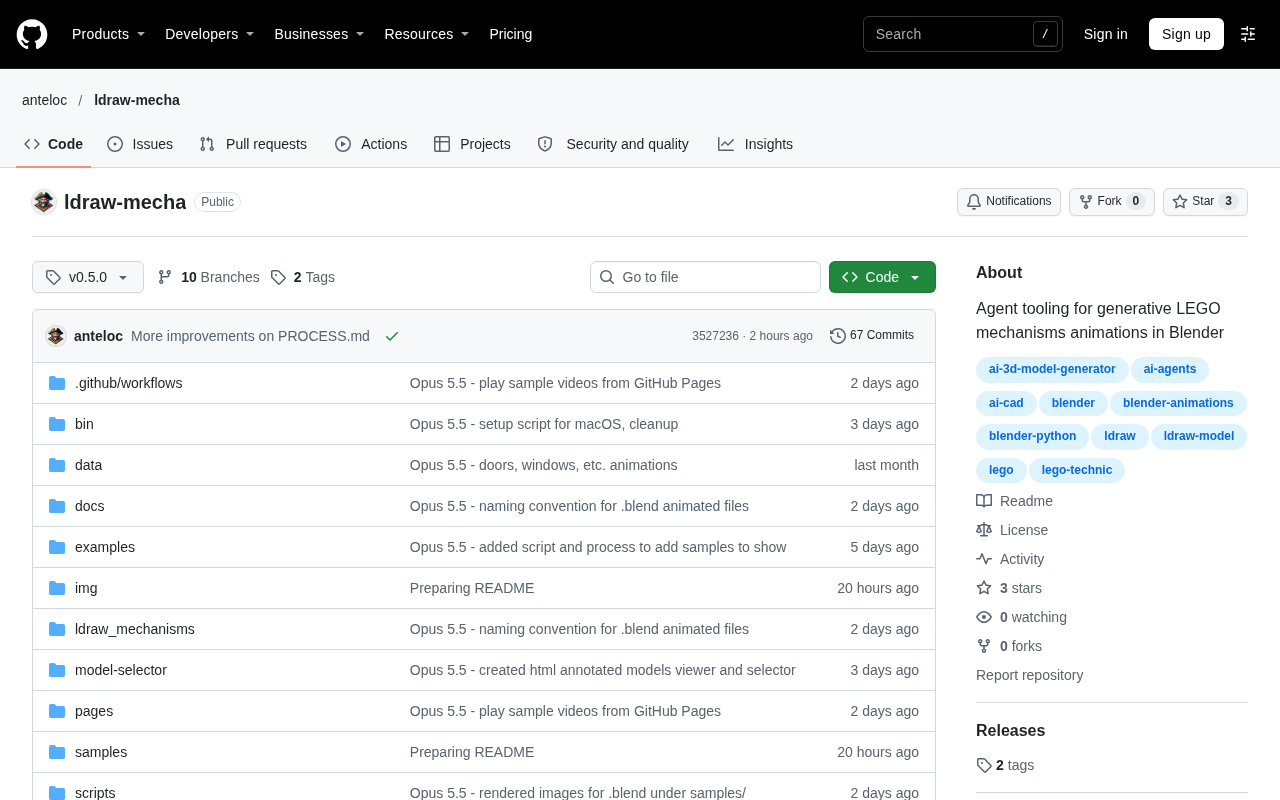
This project is worth noting because it doesn't stop at "having AI draw a Lego diagram" — it attempts to have the agent understand the motion logic behind mechanisms and present it through animation. This involves identifying and reasoning about Lego parts, connection methods, and transmission relationships, as well as how to transform static structural descriptions into dynamic temporal demonstrations.
From "Sources" to "Mechanisms": The Threshold the Agent Must Cross
The "sources" mentioned in the project description are a key but under-explained element. Literally, these sources could be official Lego instructions, parts lists, build diagrams, or some form of structured text description. The agent needs to identify components such as gears, linkages, and axles, and infer their connection relationships and motion transmission paths.
This is not a simple image recognition task. The same Lego part may serve completely different functions at different angles and in different combinations; a seemingly static build diagram implies a set of movable mechanical logic. The agent must establish a causal chain of "part—connection—motion" to accomplish the so-called "infer mechanisms." The original material does not disclose which specific model or reasoning framework it uses, but this task clearly places high demands on spatial reasoning and structured understanding.
AI Agent refers to a software system capable of perceiving its environment, performing reasoning, and autonomously taking actions to accomplish specific goals. Unlike traditional single-call models, agents typically have capabilities for task decomposition, tool invocation, multi-step planning, and self-correction. In the context of this project, the agent needs to chain together multiple subtasks: "parsing sources—identifying parts—inferring connections and transmission—generating animation." The output of each step serves as the input for the next, and it may backtrack and adjust based on intermediate results. This architecture enables it to handle open-ended, unstructured input, but also imposes higher requirements on controlling error propagation: a single deviation in early part identification could be amplified by subsequent reasoning into a completely wrong mechanism model.
Spatial Reasoning is a core capability for AI to understand the position, orientation, size, and interrelationships of objects in three-dimensional space. In Lego mechanism inference, spatial reasoning needs to address several specific problems: recovering three-dimensional assembly relationships from two-dimensional diagrams or photos; determining the contact surfaces and fit methods between parts (such as axle-hole fits and gear meshing); and distinguishing which contacts are structurally fixed and which allow relative motion. Current multimodal large models perform well in general image description, but still have obvious shortcomings in precise geometric and topological relationship reasoning, often requiring supplementation through specialized vision models, 3D reconstruction, or symbolic scene graph representations.
Making Mechanisms "Move": The Value and Challenges of Animation Generation
After inferring the mechanism, the next step is to "animate them" — turning the static mechanical structure into animation. The difficulty in this step is that the animation must be faithful to the inferred motion relationships: gear rotation directions, linkage reciprocation, and changes in transmission ratios all need to remain temporally self-consistent. If the agent merely generates an animation that visually "looks like it's moving" while ignoring mechanical constraints, the project's practical value would be greatly diminished.
From an application perspective, this capability has potential practical scenarios. For example, in Lego education or mechanical principles teaching, students could upload a build diagram and have the agent automatically generate a movable demonstration animation to help understand how the structure works. In early product design, similar reasoning and visualization workflows could also be used to quickly validate the feasibility of mechanism designs. Of course, these are reasonable extrapolations based on the project's direction; the original post does not provide specific application cases or performance data.
Kinematic Constraints describe the relative motion relationships among components in a mechanism, including degrees of freedom, joint types (revolute joints, prismatic joints, etc.), and transmission ratios. In Lego mechanisms, the gear tooth ratio determines the speed ratio and rotation direction, the length and hinge positions of linkages determine motion trajectories, and the fit between axles and holes constrains the rotation axis. For animation generation to be physically self-consistent, these constraints must be encoded as explicit equations or rules, rather than relying solely on generative models to "imitate" motion appearance from training data. A common approach is to first build a multi-body kinematic model of the mechanism, then solve for the poses of each component at each time step, and finally render it as animation; purely generative methods are prone to producing "visually plausible but physically incorrect" results that violate constraints.
The Signal Significance of a Cold-Start Project
It should be viewed objectively that the information provided by this Show HN post is quite limited. The original post does not include technical details, demo videos, or code repository links, and the comment section remains at zero replies (Comments: 0). The 13 points mean it has attracted a small amount of attention but has not yet generated community discussion.
However, from a trend perspective, the combination of "agents + mechanical reasoning + dynamic visualization" is becoming a direction worth watching. It pushes AI capabilities from text and image generation to the level of understanding physical structures and motion relationships. Even though the current project is still at an early demonstration stage, the approach it represents — having agents handle the complete chain from source parsing to dynamic demonstration — has some inspirational value for AI application developers. If the project later discloses more implementation details and interactive demonstrations, its reference value will become clearer.
Show HN is a section of the Hacker News community specifically for showcasing new projects by individuals or teams. Posters typically use the title format "Show HN: Project Name" and include a project link and brief description. The points and comment counts in this section are often used as rough signals of early project attention, but the numbers themselves are heavily influenced by posting time, title phrasing, and fluctuations in community interest; a low score does not equate to low technical value. For posts that do not yet have a code repository or demo, the community often takes a wait-and-see attitude, so zero comments is also a common phenomenon. Understanding this publishing mechanism helps to more objectively assess the amount of information conveyed by such early-stage projects.
Key Takeaways
- The project lets AI agents infer mechanical mechanisms from Lego sources and generate animated demonstrations, representing an attempt at the intersection of mechanical reasoning and dynamic visualization.
- The key challenge lies in identifying part connection relationships from static sources and inferring motion transmission logic, rather than simple image generation.
- Animation generation needs to be faithful to mechanical constraints, otherwise the visualization value is limited.
- The project received 13 points on Hacker News with no comments yet, still at an early demonstration stage, with technical details not yet disclosed.
- This direction has potential inspirational significance for Lego education, mechanical principles teaching, and rapid validation of mechanism designs.
Related articles
 Tech Frontiers
Coldframe: A Honeypot Disguised as a Supermarket Freezer Controller
Coldframe is a honeypot disguised as Danfoss AK-SM 800A and Dixell XWEB freezer controllers, built as a single Python file that detects CVE-2025-41450 attempts and is identified as real devices on Shodan.
 Tech Frontiers
GRFNet: A Lightweight PyTorch Model Designed for Multichannel Time-Series Classification
GRFNet is a lightweight PyTorch model for multichannel time-series classification, originating from EEG decoding research. With only 3,847 parameters, it is based on the ROCKET architecture, combining random convolution kernels with learnable spatial filters, supports arbitrary input lengths, and will soon be evaluated on the PhysioNet dataset.
 Tech Frontiers
CUDA-Accelerated Rocket League Simulator: A Player-Made Hardcore Experiment
A Reddit post shows a "100% Accurate" Rocket League simulator accelerated with CUDA. We analyze its technical context, CUDA's value in game physics simulation, and the significance and limitations of such community projects.