Why Are We Obsessed with Humanoid Robots?
Though not the most efficient, humanoid robots have unique value in general-purpose scenarios thanks to environmental adaptability and data reuse.
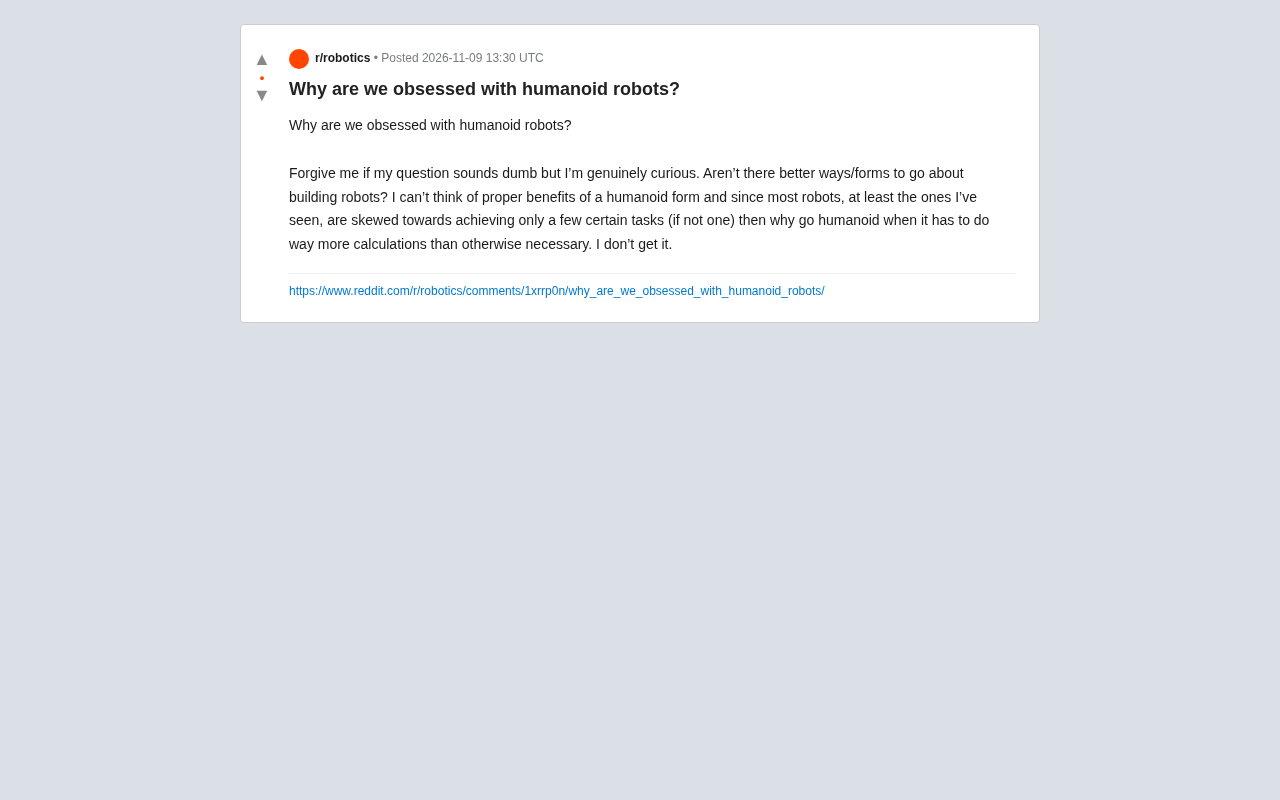
Starting from the Reddit question "why insist on building humanoid robots," the article outlines the arguments for and against the humanoid form. Supporters argue that the human world was designed for the human body, so humanoid robots can directly use existing tools and facilities without modifying the environment, and their joint structure is similar to humans, making it easy to reuse massive amounts of human behavioral data and reduce cross-embodiment transfer costs. Opponents point out that the humanoid structure brings higher balance computation and hardware costs, and specialized robots are cheaper and more reliable on single tasks. Capital and public preference for humanoids has both dissemination and psychological reasons, and may also divert resources from more pragmatic automation solutions. The article concludes that the debate over approaches is unsettled, and multiple forms are more likely to coexist in the future.
Humanoid robots have been getting a lot of attention lately—from factory assembly lines to home services, it seems like a new demo goes viral every few weeks. But a question from a Reddit user captures what many people are wondering: given that the vast majority of robots focus on just a few specific tasks, why insist on building them to look like humans? After all, a humanoid structure means more balance computation, higher hardware costs, and more complex control algorithms. This seemingly "silly" question actually touches on the most fundamental debate in robotics.
The Hidden Advantage of Humanoid Form: Environmental Compatibility
From an engineering perspective, the humanoid form is certainly not the most efficient solution. Wheeled bases are more stable, robotic arms are more precise, and specialized robots (like robot vacuums and welding robots) far outperform general-purpose humanoids on single tasks. But supporters of humanoid robots argue that the world we live in was designed for the human body. The height of door handles, the dimensions of stair steps, the way tools are gripped—all of it revolves around human size and movement capabilities.
This means a truly general-purpose humanoid robot can go straight to "work" without modifying the environment. Factories can use it to operate existing human-machine interfaces, and households can have it use ready-made tools like vacuum cleaners and microwaves. By contrast, non-humanoid general-purpose robots often require corresponding modifications to the work environment, with high hidden costs. This potential for "zero-modification adaptation" is the most underappreciated value of the humanoid form.
Embodied Intelligence is important context for understanding this debate over approaches. This concept emphasizes that intelligence cannot exist independently of the body—a robot's cognitive and motor abilities are closely tied to its physical form. Different body structures determine what a robot can perceive and do, which in turn affects its learning methods and task scope. The rationale for humanoid robots is precisely based on the embodied intelligence perspective: tools, facilities, and interaction methods in human environments evolved around the human body, and an agent with a body structure similar to humans naturally has a priori advantages in perception and manipulation that are compatible with these environments. This also explains why morphological choice is not just a hardware issue, but a fundamental decision that directly affects whether an agent can efficiently interact with the human world.
The Data-Driven Shortcut: Human Data Can Be Directly Reused
Another often overlooked factor is data. Current AI progress relies heavily on large-scale human behavior data—video, motion capture, teleoperation records. The joint structure and kinematics of humanoid robots are similar to those of humans, which means the cost of transferring from human data to robot policies is lower.
If you switch to a quadruped or wheeled structure, the same data requires additional retargeting and mapping, and the results often suffer. Some research teams have tried training robot manipulation skills using first-person human video, and humanoid platforms show more natural generalization. In other words, the humanoid form is not the goal, but a means of letting robots "inherit" the behavioral data humans have accumulated.
Retargeting is a key technical concept in robot learning, referring to the process of mapping motion data from one kinematic structure (such as a human skeleton) to another structure (such as a robot's joint space). Because humans and humanoid robots are highly similar in joint count, limb proportions, and range of motion, this mapping can be done directly through joint correspondences with relatively small error. If the target platform is a quadruped or wheeled robot, however, it lacks corresponding upper-limb joints or degrees of freedom, requiring additional inverse kinematics solving and motion abstraction, which can easily lose details or introduce unnatural postures during mapping. This is precisely the core engineering advantage of the humanoid form for data reuse: it minimizes the difficulty of the "cross-embodiment transfer" problem, allowing massive amounts of human video and motion capture data to be converted into robot-executable policies with lower loss.
Business and Psychology: Why Humanoids Attract More Capital
Setting aside technical rationality, humanoid robots receive far more attention than other forms, and there are both business and psychological reasons behind this. On one hand, humanoid robots are naturally suited to demonstration and dissemination—they can walk, grasp, and interact with people, making for highly effective viral videos that easily attract investment and public imagination. On the other hand, humans have an instinctive affinity for machines that "look like us," which is a real advantage in service, education, and companionship scenarios.
But this is also exactly where the controversy lies. In the discussion under the original Reddit post, some users pointed out that humanoid robots easily create unrealistic expectations, while in actual deployment, specialized robots are often cheaper and more reliable. Capital chasing humanoids may divert resources away from more pragmatic automation solutions.
The Uncanny Valley effect is a key concept for understanding the psychological acceptance of humanoid robots, proposed by Japanese roboticist Masahiro Mori in 1970. The theory states that when a robot's appearance and movements approach but do not fully achieve human realism, people feel uneasy or even repulsed; when similarity continues to increase to near-human levels, affinity rises again. This means the psychological advantage of humanoid robots does not grow linearly—there is a sensitive zone. Most current humanoid robots are at a medium-similarity stage, and overly realistic appearances may backfire. Therefore, in scenarios such as service and education, how to balance "human enough" to build affinity and "not too human" to avoid the uncanny valley is a practical challenge in humanoid robot product design and an important dimension for evaluating commercial viability.
The Debate Over Approaches Is Far from Settled
There is no consensus on whether humanoid robots are worth investing in. Supporters value generality and environmental compatibility, while opponents emphasize efficiency and cost. A balanced judgment is: the humanoid form has unique value in scenarios that require high generality and shared human spaces, but offers no advantage in structured, single-task scenarios. The more likely future is a coexistence of multiple forms rather than humanoids dominating everything.
For the average observer, the key to understanding this debate is distinguishing between "technical feasibility" and "commercial narrative." Humanoid robots are both an engineering choice and a social experiment about how humans imagine automation.
Frequently Asked Questions
Q: Are humanoid robots more expensive than specialized robots? A: Generally yes. The humanoid structure requires more joints and more complex balance control, and hardware and maintenance costs are typically higher than single-task robots, but generality may amortize long-term deployment costs.
Q: Why not use a wheeled base with a robotic arm? A: This is another pragmatic approach that is more efficient in flat environments. The disagreement is over whether to adapt to human environments such as stairs and narrow spaces, which determines the morphological choice.
Q: What can humanoid robots do now? A: Current public demonstrations mostly focus on tasks like carrying, sorting, and simple manipulation. Complex home services are still in an early exploratory stage, and reliability and cost remain bottlenecks.
One-line Summary
Although humanoid robots are not the most efficient, they have unique value in general-purpose scenarios thanks to environmental compatibility and data reuse advantages.
Paragraph Summary
Starting from the Reddit question "why insist on building humanoid robots," the article outlines the arguments for and against the humanoid form. Supporters argue that the human world was designed for the human body, so humanoid robots can directly use existing tools and facilities without modifying the environment, and their joint structure is similar to humans, making it easy to reuse massive amounts of human behavioral data and reduce cross-embodiment transfer costs. Opponents point out that the humanoid structure brings higher balance computation and hardware costs, and specialized robots are cheaper and more reliable on single tasks. Capital and public preference for humanoids has both dissemination and psychological reasons, and may also divert resources from more pragmatic automation solutions. The article concludes that the debate over approaches is unsettled, and multiple forms are more likely to coexist in the future.
Related articles
GPT-6 Security Model and the AI Attack-Defense Escalation: This Week in AI
This week in AI: OpenAI's GPT-6 Saber found 948 Linux kernel root-escalation paths; Cursor deploys full apps from one sentence; Binance details a social engineering attack; C++26 fails ISO vote.
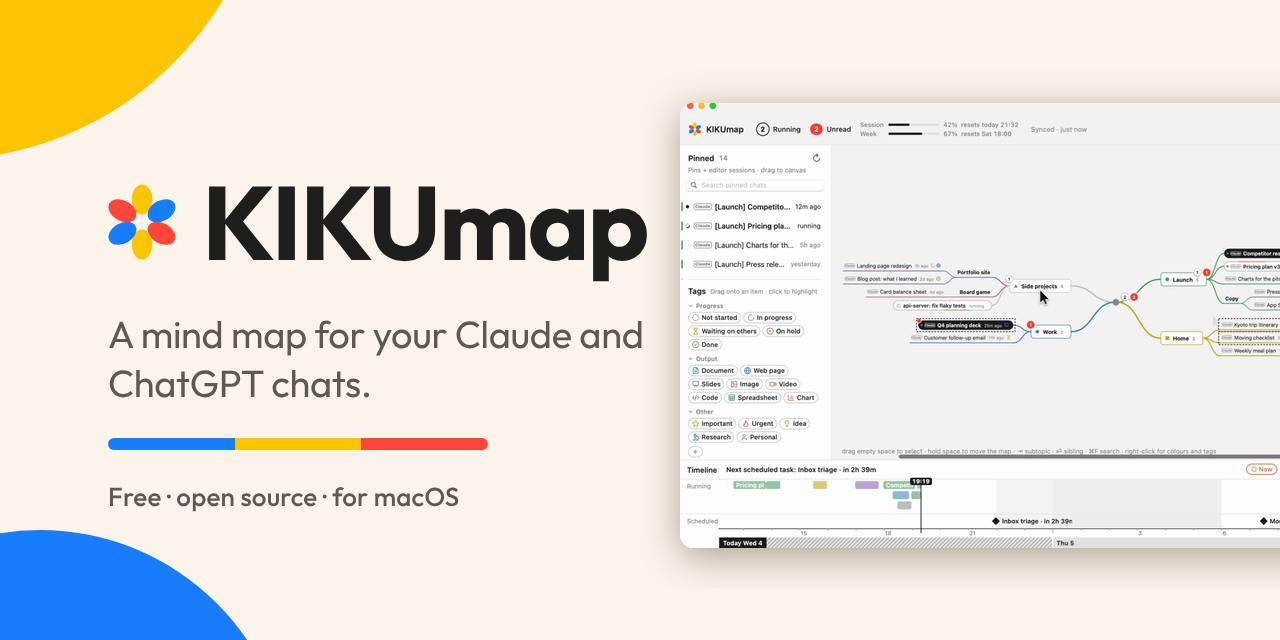
KIKUmap: Manage Your Claude and ChatGPT Conversations with Mind Maps
KIKUmap is a macOS menu bar app that visualizes Claude and ChatGPT conversations as mind maps with real-time status. Free and open source.

Hugging Face Executive Warns: Cyberattacks Are Eroding the Openness of Open-Source AI
Hugging Face executive Irene Solaiman warns that rising cyberattacks on open AI platforms may force stricter security limits, threatening the openness of the open-source community and affecting the developer ecosystem.