CBR-II Robot V3 Update: Smoother Gait and a One-Leg Stand Attempt

Open-source bipedal robot CBR-II releases V3 with smoother gait and a one-leg standing attempt.
A Reddit user shared the V3 update of open-source bipedal robot CBR-II, featuring smoother gait control and an initial one-leg standing attempt. The article analyzes that gait smoothness may come from trajectory interpolation or impedance control optimization, while one-leg standing involves real-time IMU processing, ZMP planning, and rapid torque response. The project's continuous open updates highlight how community collaboration accelerates technology diffusion, and low-cost servos, inertial sensors, and tools like ROS 2 and PyBullet enable individual developers to tackle complex locomotion control, offering a reference for educational robotics projects.
In the context of rapidly iterating robotics technology, the open-source community once again demonstrates strong innovative vitality. Recently, a Reddit community user shared the V3 update of the CBR-II robot project, highlighting smoother gait control and an initial attempt at one-leg standing tests. This progress not only reflects individual developers' deep exploration of bipedal robot locomotion control but also provides valuable reference cases for enthusiasts.
Gait Optimization: From "Can Walk" to "Walks Steadily"
According to the Reddit post, one of the core improvements in CBR-II V3 is a smoother gait. In the field of bipedal robots, gait smoothness directly affects walking stability and energy efficiency. In earlier versions, the robot often exhibited noticeable jerkiness while walking, typically stemming from insufficiently continuous joint trajectory planning or controller response delays. By adjusting the control algorithm, V3 may have introduced finer trajectory interpolation or impedance control strategies, making foot landing and center-of-mass transfer more coherent.
Although the post does not disclose specific technical details, the phrase "smoother gait" suggests that the developer optimized the motor control loop or gait state machine. For hobbyist robotics projects, such improvements often require repeated tuning of PID parameters or introducing feedforward compensation to offset the inertia and friction of the mechanical structure. A smooth gait is not only a visual improvement but also a sign of enhanced dynamic balance capability.
Impedance Control is a control strategy that achieves compliant interaction by adjusting the "virtual stiffness and damping" of robot joints. Unlike traditional position control, it does not force joints to follow precise trajectories but allows them to deviate when external forces are applied, thereby absorbing impacts, reducing mechanical wear, and making foot landing more natural. In bipedal robots, impedance control is often used during the swing-leg landing phase: the controller dynamically adjusts joint torques based on the desired relationship between foot force and position, enabling the robot to "land softly" like a spring—this is precisely an important source of gait smoothness. If CBR-II V3 introduced such a strategy, it could significantly improve walking coherence without increasing hardware costs.
One-Leg Standing: A New Challenge in Balance Control
Another highlight of V3 is the attempt at one-leg standing. One-leg standing is a classic challenge in bipedal robot balance control, requiring the robot to maintain center-of-mass stability with only a single point of support. This involves real-time processing of IMU (Inertial Measurement Unit) data, dynamic adjustment of the center-of-mass projection point, and rapid response of joint torques. The phrase "trying to stand on one leg" in the post title indicates that this feature is still experimental and may not yet be fully successful, but the attempt itself marks the project's move from basic walking toward higher-level dynamic balance.
In the open-source robotics community, one-leg standing is often used as a test case to verify the robustness of control algorithms. Successful one-leg standing requires the robot to have rapid attitude perception and feedback capabilities, typically combining Kalman filtering for state estimation and adopting model predictive control or Zero Moment Point (ZMP) planning to maintain stability. CBR-II's attempt lays the foundation for subsequently achieving dynamic motions such as jumping and running.
Zero Moment Point (ZMP) is a core concept in bipedal robot balance analysis, referring to the point on the ground where the resultant moment of gravity and inertial forces acting on the robot is zero. As long as the ZMP remains within the support polygon (the foot contact area during one-leg standing), the robot will not tip over. ZMP-based planning methods typically generate center-of-mass trajectories satisfying ZMP constraints offline and then solve for joint angles via inverse kinematics. For scenarios with extremely small support areas such as one-leg standing, the allowable ZMP range is very limited, requiring high-frequency state estimation and torque response. If CBR-II's attempt combines ZMP planning with IMU feedback, it can provide a theoretical framework for subsequent dynamic gaits.
The Value of Community-Driven Innovation
The CBR-II project continuously updates through platforms such as Reddit, demonstrating the unique advantages of open-source hardware and community collaboration. Developers openly share progress and challenges, which not only garners feedback but also inspires other enthusiasts to reproduce and improve. This model accelerates technology diffusion, ensuring that bipedal robot technology is no longer confined to large laboratories.
From an industry perspective, individual developers' ability to achieve smooth gaits and one-leg standing attempts benefits from the proliferation of low-cost, high-performance servo motors, inertial sensors, and open-source control libraries (such as ROS 2 and the PyBullet simulation environment) in recent years. CBR-II's iteration path also provides a reference for educational robotics projects: gradually increasing complexity from basic locomotion to dynamic balance while maintaining openness of code and hardware.
ROS 2 (Robot Operating System 2) is the de facto standard for open-source robotics middleware, providing foundational capabilities such as node communication, hardware abstraction, sensor drivers, and visualization tools. PyBullet is a lightweight physics simulation engine that supports rigid body dynamics, joint constraints, and sensor simulation, commonly used to validate gait algorithms without risking damage to physical hardware. The combination of the two enables individual developers to rapidly iterate control parameters in simulation environments and then deploy validated strategies onto physical robots. The CBR-II project's ability to continuously update largely benefits from such open-source toolchains lowering the barrier to locomotion control development, enabling hobbyist teams to reproduce laboratory-level debugging workflows.
Future Outlook
Although the V3 update does not provide detailed technical documentation, it sends a clear signal: CBR-II is evolving toward more natural and stable locomotion capabilities. Next, the developer may focus on closed-loop control tuning for one-leg standing or introduce more advanced gait planning algorithms. For readers interested in bipedal robot technology, continuously following the project's subsequent updates will help understand how hobbyist teams tackle dynamic balance challenges.
Overall, the CBR-II V3 update is a solid step forward for the open-source robotics community, with smoother gait and one-leg standing attempts accumulating valuable experience for future development. As more details are disclosed, the project is expected to become an excellent case for both introductory and advanced learning in bipedal robotics.
One-line Summary
Open-source bipedal robot CBR-II releases V3, achieving smoother gait and attempting one-leg standing.
Paragraph Summary
A Reddit community user shared the V3 update of the open-source bipedal robot CBR-II, with core improvements including smoother gait control and an initial one-leg standing attempt. The article analyzes that the improved gait smoothness may stem from optimized trajectory interpolation or impedance control strategies, while one-leg standing involves dynamic balance techniques such as real-time IMU processing, ZMP planning, and rapid torque response. The project continuously discloses progress through community platforms, demonstrating the value of open-source collaboration in accelerating technology diffusion. The proliferation of low-cost servo motors, inertial sensors, and open-source tools such as ROS 2 and PyBullet enables individual developers to tackle complex locomotion control, and CBR-II's iteration path also provides a reference example for educational robotics projects from basic locomotion to dynamic balance.
Related articles
Getting Started with DeepSeek Harness: A Full Breakdown of Agents, Skills, MCP, and Plugins
What's the difference between Agent, Skill, MCP, and plugins in DeepSeek Harness? A hands-on comparison and assistant analogy explain their roles, context overhead, and how to choose.
The AI Comic Drama Hit Formula: A Four-Line Checklist and a Full Doubao Walkthrough
Final Bilibili hit-breakdown episode: a four-line AI comic drama formula combining script, character, emotion, and hook, with a live Doubao walkthrough, five validation criteria, and upscaling/storyboard tips.
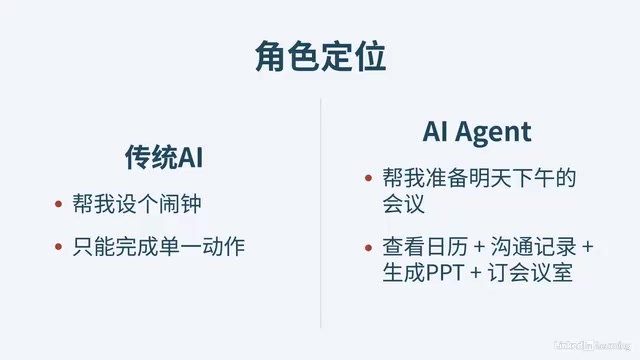
AI Agent Quick-Start Guide: A Complete Breakdown from Concept to Practice
Based on Bilibili's AI Agent Quick-Start course, this guide covers the definition, three core capabilities, workflow, history, and five types of AI Agents, plus real-world boundaries like understanding failures, memory errors, tool call breakdowns, and permission overreach, with a component checklist and practical advice.